Advanced Navigation has demonstrated its inertial-centric navigation architecture during the U.S. Army’s All-Domain Persistent Experiment (APEX), recording a final dead-reckoning error of 0.012% over a 65 km route with its Boreas D90 and Laser Velocity Sensor (LVS) configuration under GNSS jamming conditions.
The demonstration evaluated its multi-sensor approach to assured Positioning, Navigation and Timing (PNT) in a contested electromagnetic environment.
The U.S. Army’s APEX program evaluates mission resilience across technologies including assured PNT, integrated sensing, advanced communications, data transport and edge processing. Advanced Navigation has participated in the program for three years, testing its systems under realistic Electromagnetic Warfare conditions.
In Degraded, Denied, Intermittent and Low-bandwidth (DDIL) environments, adversaries actively deny, degrade and spoof GNSS signals. Reliance on a single navigation technology creates a potential mission-ending vulnerability, highlighting the need for reliable, high-accuracy PNT when external signals are compromised.
Advanced Navigation demonstrated an intelligent navigation architecture built around a resilient inertial core supported by complementary aiding sensors. The configuration incorporated four components:
- Boreas D90: A Fiber Optic Gyroscope Inertial Navigation System (INS) enabling independent, high-confidence navigation without reliance on GNSS or magnetic compasses.
- AdNav Intelligence: Adaptive software that continuously validates sensor inputs, dynamically weights their contributions according to reliability scores and environmental context, and autonomously counteracts spoofing and jamming.
- Chimera Land: A LVS that enables uncompromised dead-reckoning reliability and is built for operational environments where GNSS is compromised or denied.
- Wheel Speed Encoder: Measures wheel rotation to calculate vehicle speed, providing independent velocity updates to the INS to constrain accumulated drift.
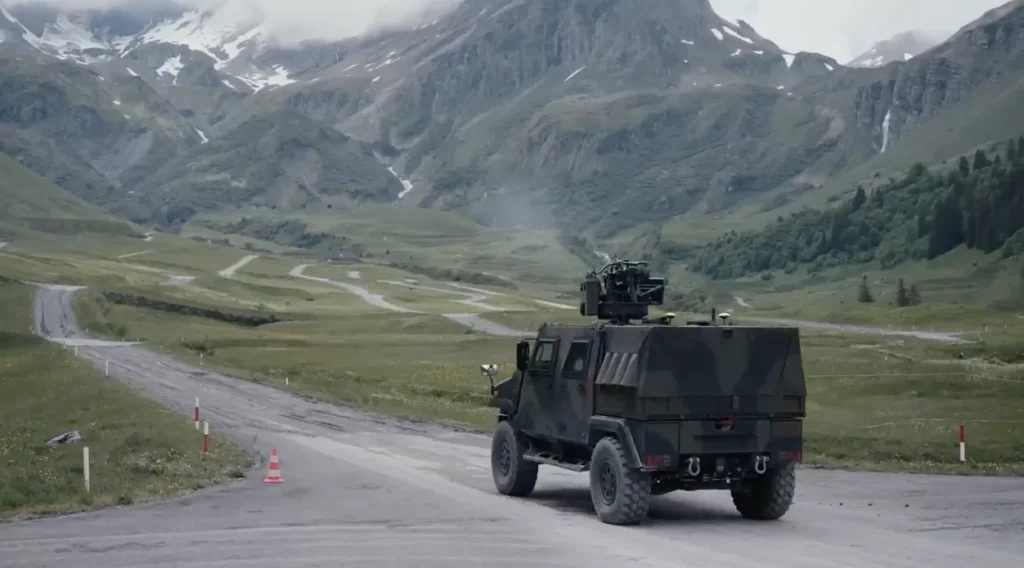
The APEX demonstration took place during night operations at a rural site in New Mexico, USA, where event organizers conducted GNSS jamming to create an environment of complex and emerging Electromagnetic Warfare threats.
Advanced Navigation reported dead-reckoning results over a 65 km route using two INS aiding configurations: Boreas D90 with a Laser Velocity Sensor and Boreas D90 with a wheel speed encoder.
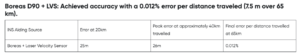
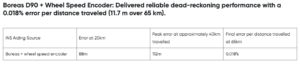
The APEX results validated Advanced Navigation’s intelligent, inertial-centric multi-sensor approach as a resilient foundation for assured PNT, demonstrating dead-reckoning performance under the GNSS jamming conditions established during the exercise.