Photonic Inertial Sensing for Drones & Unmanned Systems
OSCP’s photonic gyroscope technology measures rotation using the Sagnac effect. Light travels around an optical path in opposite directions, with rotation producing a phase difference between the two beams. This optical path has been miniaturized and incorporated onto a chip thanks to cutting-edge semiconductor processes, doing away with the need for hundreds of meters of precision-wound optical fiber.
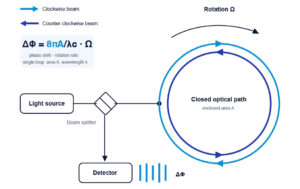
The sensing path has no moving parts and is highly resistant to vibration and electromagnetic interference, making it ideal for unmanned platforms operating in harsh environments. The MK2E2 and MK2Z combine an optical Z-axis gyroscope with a MEMS inertial sensor suite, providing enhanced heading-axis performance. The MK2M2 uses MEMS sensing throughout for applications where compact dimensions, low weight and unit cost are key requirements.
The photonic architecture is designed to reduce size, weight and power compared with traditional fibre-optic gyros.
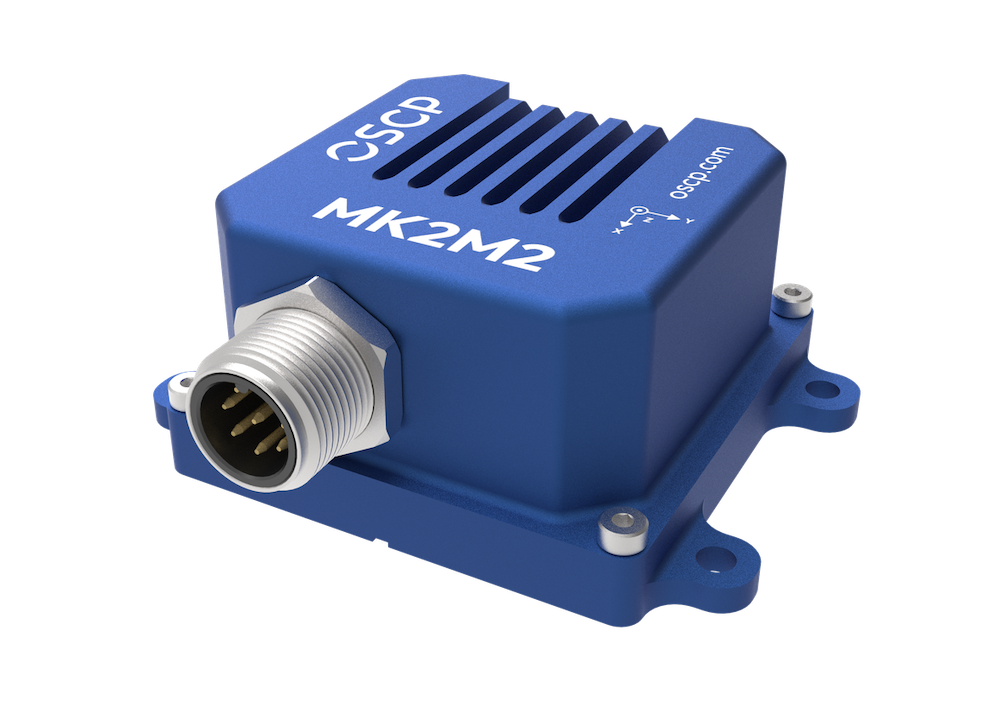
MK2M2
Compact tactical-grade 11-DoF MEMS IMU
The MK2M2 is an 11-DoF MEMS IMU incorporating three-axis gyroscopes, three-axis accelerometers, a three-axis magnetometer and two-axis inclinometers. Measuring just 40 × 40 × 25 mm and weighing 75 g, the unit is ideal for drone autopilots, ground robotics, and SWaP-conscious applications where GNSS is available most of the time.
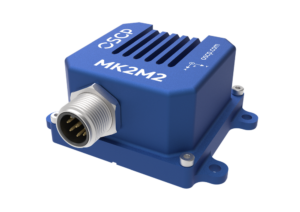 The IP67-certified housing protects the IMU in demanding operating environments, and the system has been tested to DO-160 style profiles at 2, 4 and 8 g vibration and 20 g and 40 g shock. Each unit is factory-calibrated for offset, scale factor and misalignment, as well as magnetometer hard- and soft-iron effects.
- 40 × 40 × 25 mm, 75 g, 1.2W
- Gyro in-run bias stability: <1.0 °/hr typical, 0.5 °/hr minimum
- ARW: 0.06 °/√hr
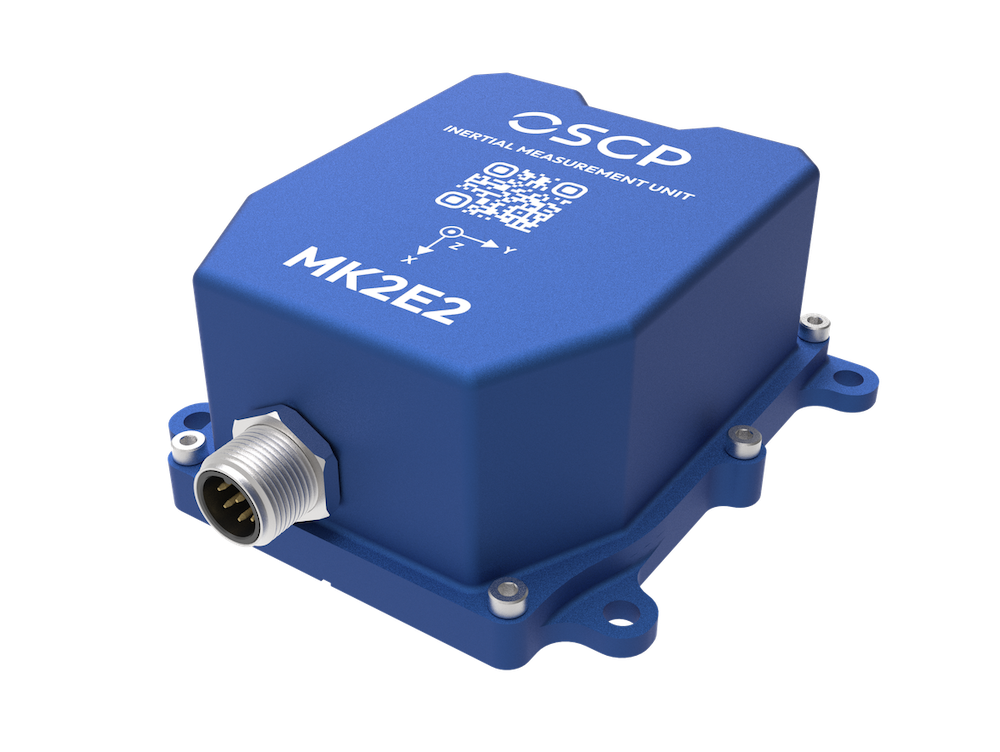
MK2E2
Hybrid photonic 11-DoF IMU with optical Z axis
The MK2E2 is an 11-DoF hybrid IMU pairing a photonic integrated-circuit optical gyroscope with MEMS gyroscopes, accelerometers, magnetometers and inclinometers. The MK2E2 is intended for applications where GNSS outages may last minutes, making the sensor ideal for operation in contested conditions, urban canyons, or high levels of vegetation.
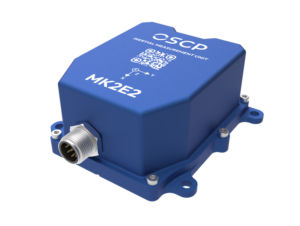 The rugged unit’s optical sensing path has no moving mass, reducing susceptibility to vibration-induced errors. It is enclosed in a robust IP57-rated housing, with IP67 certification in progress.
- 78 x 63 x 36 mm, 230 g, 2 W
- Gyro in-run bias stability (optical Z axis): <1.0 °/hr typical, 0.5 °/hr minimum
- Gyro in-run bias stability (MEMS X, Y and Z axes): <1.0 °/hr typical, 0.5 °/hr minimum
- ARW (optical Z axis): 0.03 °/√hr
- ARW (MEMS X, Y and Z axes): 0.06 °/√hr
Road-test comparison
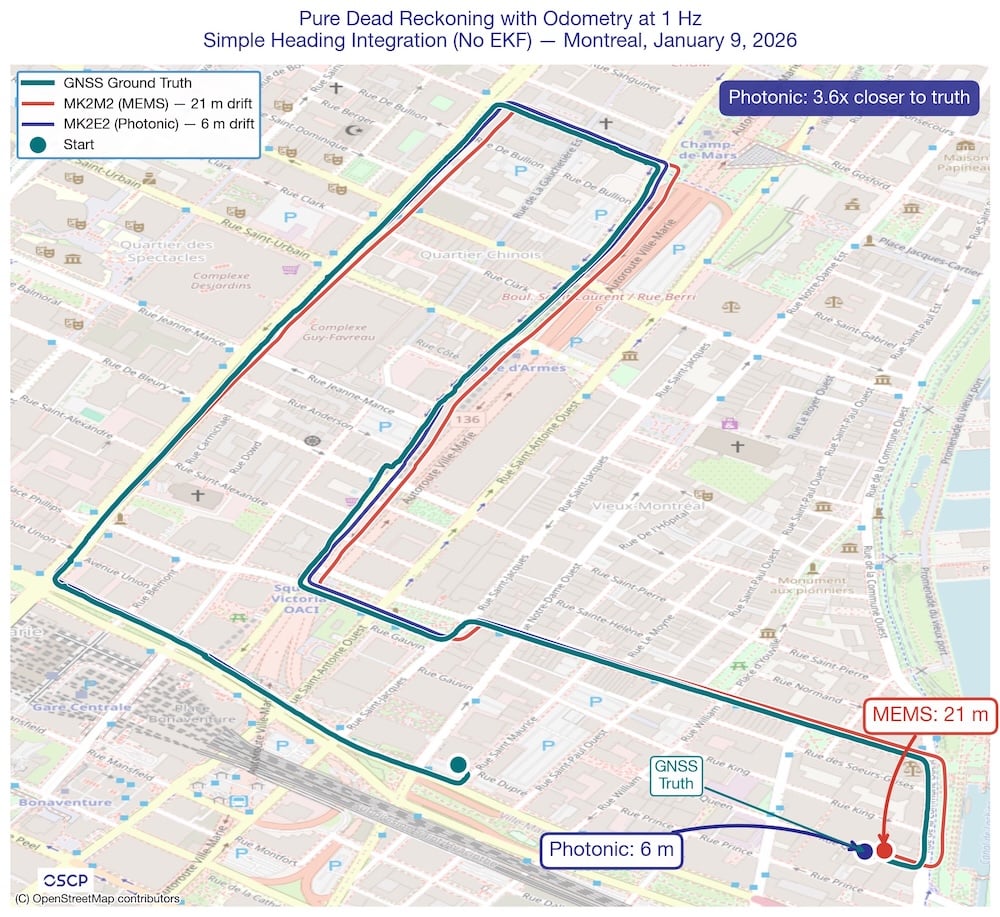
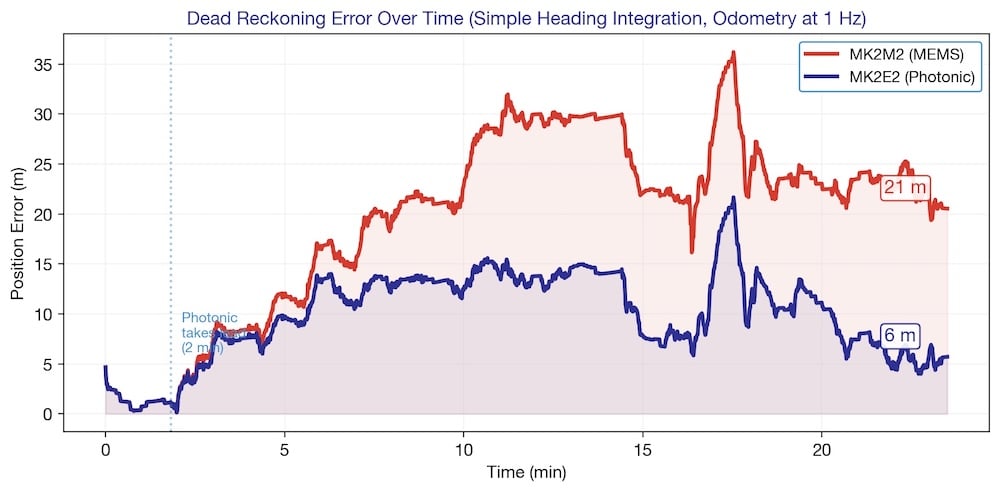
OSCP compared the MK2E2 and MK2M2 during a 21-minute road test through Montreal. Both units were mounted in the same vehicle and logged at 100 Hz. Heading was calculated from each unit’s Z-axis gyro, and position was calculated using odometry at 1 Hz. GNSS position was withheld from both navigation solutions and used afterward as the reference. No EKF, map matching, or zero-velocity updates were used.
At the end of the drive, the MK2E2 recorded a final horizontal position error of 5.7 m, compared with 20.5 m for the MK2M2. The MK2M2’s final error was approximately 3.6 times the MK2E2’s in this test.
Read the full road-test case study
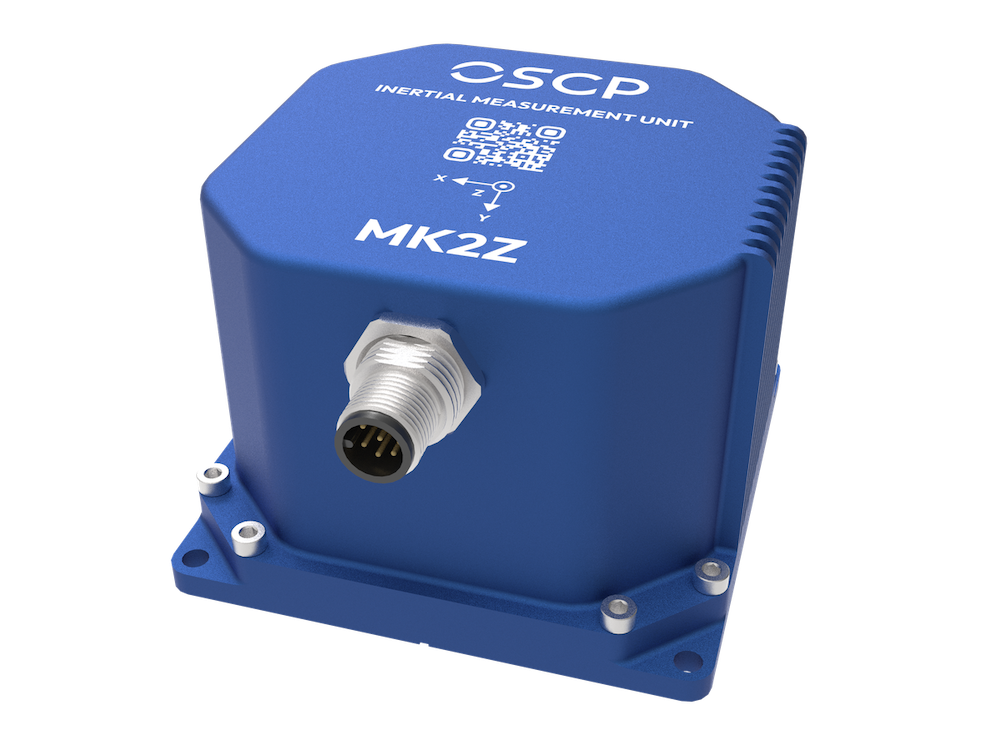
MK2Z
Navigation-grade hybrid photonic IMU
The MK2Z is a hybrid photonic IMU featuring a navigation-grade optical gyroscope on the Z axis alongside MEMS gyroscopes, accelerometers, magnetometers and inclinometers. Designed for demanding applications requiring long-term heading stability and low-drift during GNSS interruptions, it is highly suited to unmanned systems in all domains.
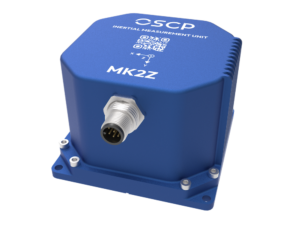 Currently in prototype stages, the MK2Z is available now for early-access evaluation – contact OSCP to find out more.
- 83 × 86.5 × 65 mm, 475 g, 4.5–7.5 W
- Gyro in-run bias stability (optical Z axis): <0.01 °/hr typical, 0.005 °/hr minimum
- Gyro in-run bias stability (MEMS X, Y and Z axes): 0.5 to <1.0 °/hr
- ARW (optical Z axis): 0.02 °/√hr
- ARW (MEMS X, Y and Z axes): 0.06 °/√hr
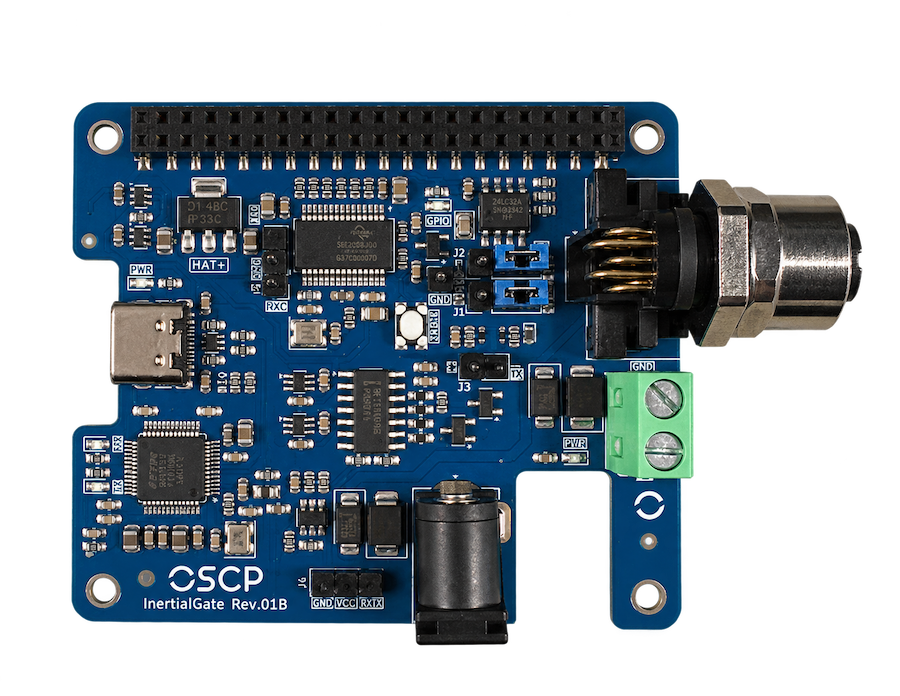
InertialGate
Evaluation & gateway kit for MK2 IMUs
InertialGate is an evaluation and gateway board for the MK2 family, allowing developers to quickly and conveniently connect an IMU to a host system without needing to design a dedicated interface. With a footprint of just 57 x 66 mm, it easily drops into existing bench setups or enclosures.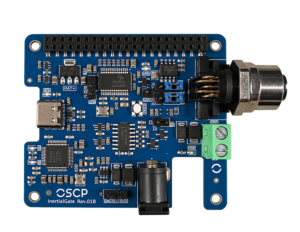
The compact plug-and-play board provides RS-422 and CAN-FD connectivity, with RS-422 data accessible on a computer through a virtual COM port over USB-C. Raspberry Pi HAT+ compatibility and development headers enable connections to embedded and custom platforms.




 verified