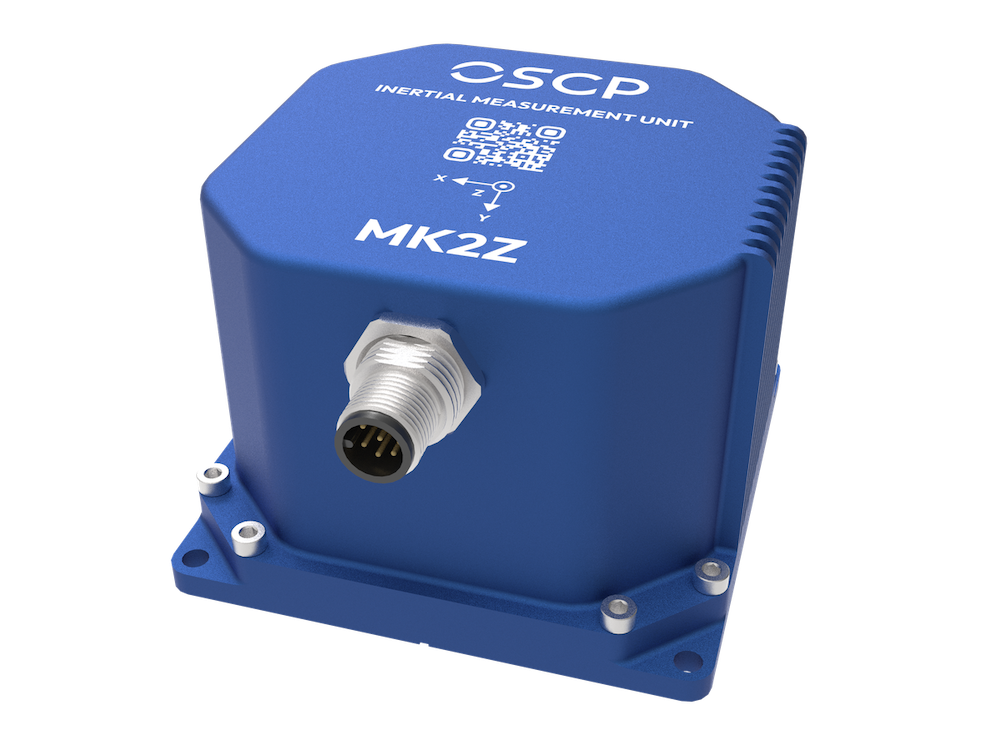
MK2Z
The MK2Z is a hybrid photonic IMU prototype featuring a navigation-grade optical gyroscope on the Z axis alongside MEMS gyroscopes, accelerometers, magnetometers and inclinometers. It is designed for demanding unmanned applications requiring low drift and long-term heading stability during GNSS interruptions.
The ITAR-free unit is available for early-access evaluation and provides sensor data over RS-422 or CAN-FD. Its optical Z-axis performance is distinct from that of the MEMS gyroscopes, with substantially lower in-run bias instability. All specifications below are preliminary and subject to change.
Specifications:
| Dimensions | 83 × 86.5 × 65 mm body; 90 × 90 × 65 mm with flanges |
| Weight | 475 g |
| Power consumption | 4.5 W typical; 7.5 W maximum |
| Supply voltage | 12–34 V |
| Optical gyro range, Z axis | ±250°/s |
| Optical gyro in-run bias stability, Z axis | 0.005 to <0.01°/hr |
| Optical gyro angle random walk, Z axis | 0.02–0.03°/√hr |
| MEMS gyro range | ±125 to ±4000°/s |
| MEMS gyro in-run bias stability | 0.5 to <1.0°/hr |
| MEMS gyro angle random walk | 0.06°/√hr |
| Accelerometer range | ±2, ±4, ±8, ±16 g |
| Accelerometer bias stability | <15 µg |
| Accelerometer velocity random walk | 0.008 m/s/√hr |
| Magnetometer range | ±20 G |
| Inclinometer range | ±0.5, ±1, ±2, ±3 g |
| Interfaces | RS-422 or CAN-FD |
| Output data rate | Up to 500 Hz |
| Ingress protection | IP67 certification in progress |
| Product status | Prototype; early-access evaluation |