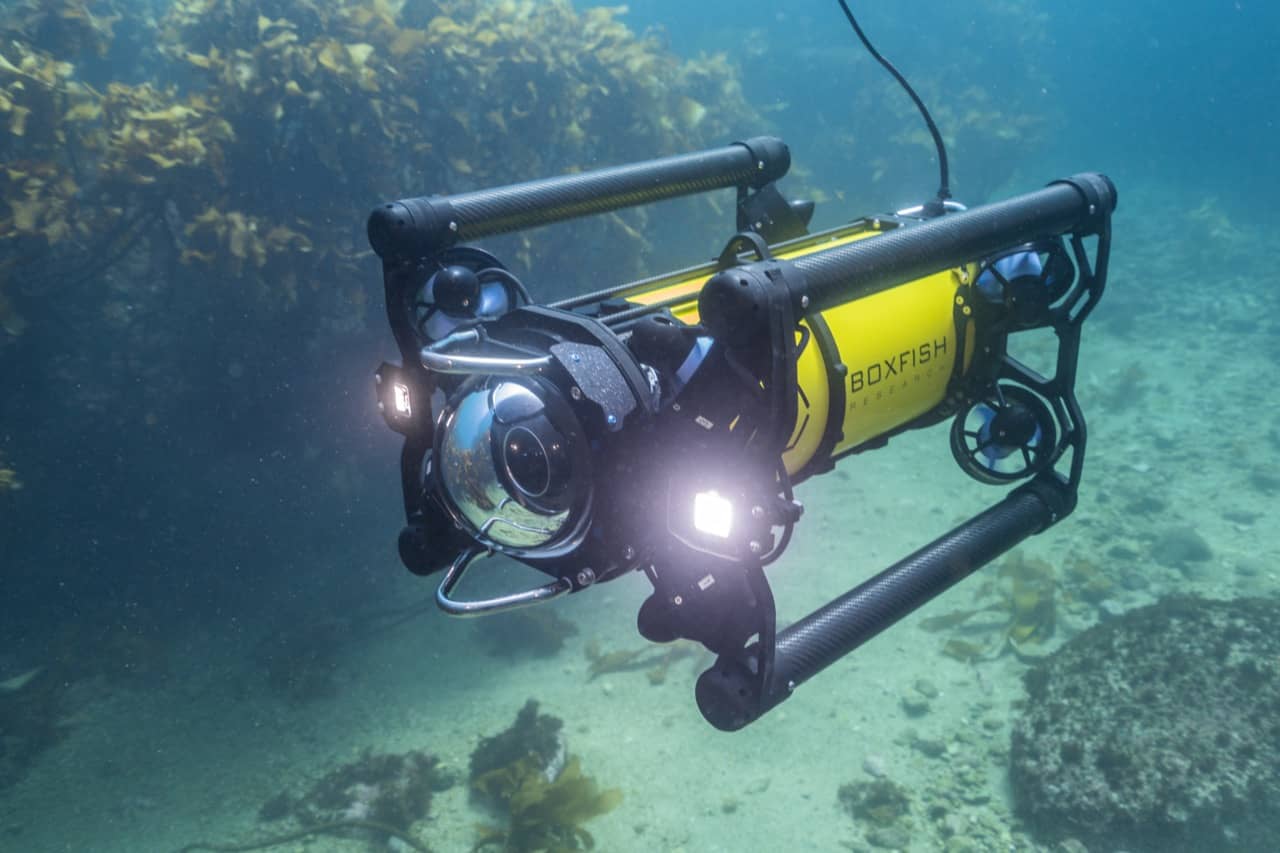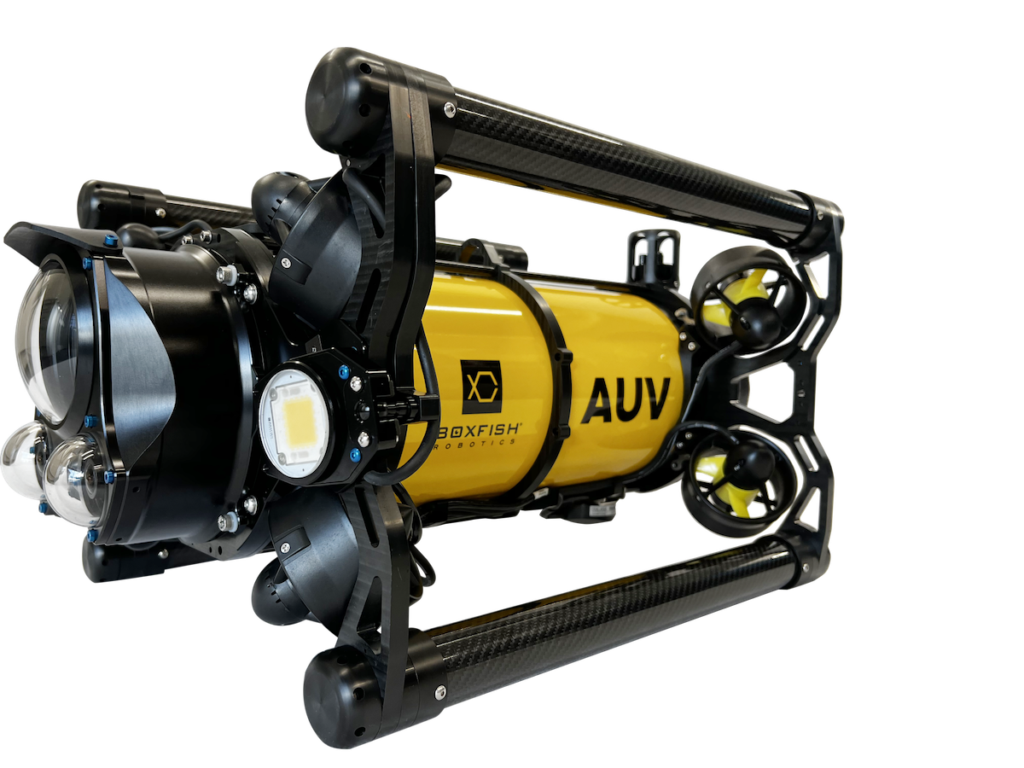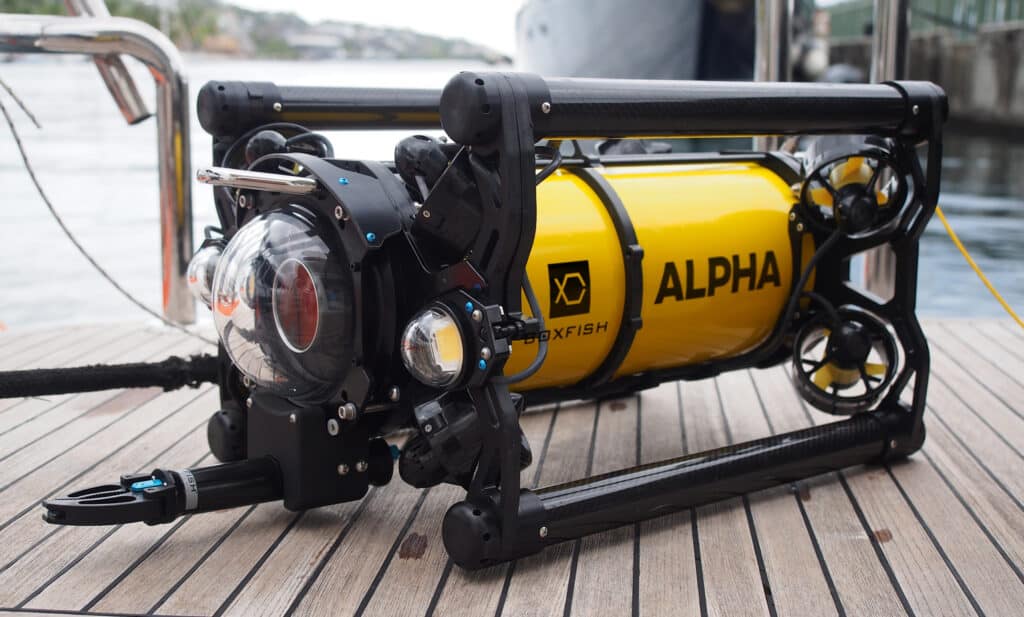
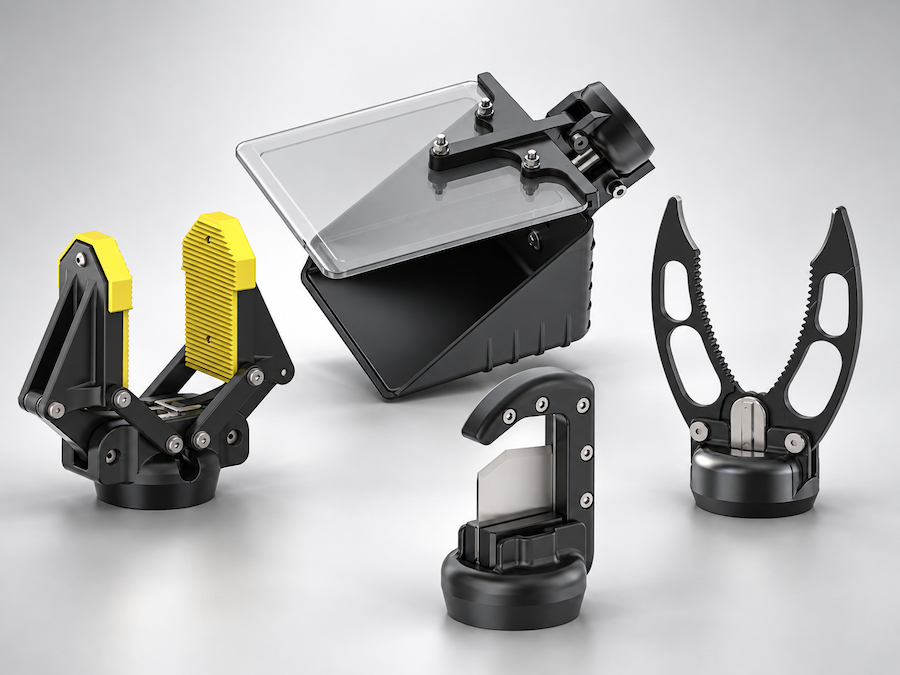
Boxfish Robotics has released the Boxfish Multitool, an underwater intervention tool platform designed to expand the range of tasks that can be carried out using Remotely Operated Vehicles (ROVs).
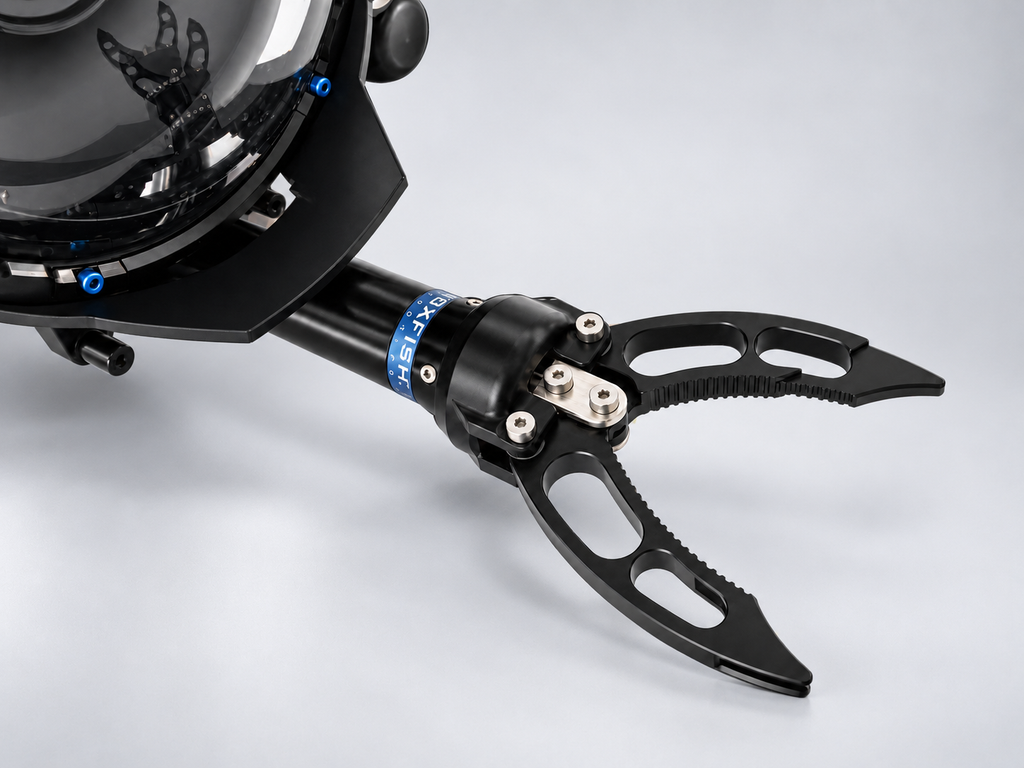
The system uses interchangeable end effectors, allowing operators to configure the same tool platform for different missions while retaining the same integrated mechanical, electrical and control system. This reduces vehicle reconfiguration and simplifies preparation for different tasks.
Standard jaws are the Multitool’s default tool, providing a grip force of 300 N and a hold force of 450 N. Additional available end effectors include parallel jaws, a cutter and a sediment sampler. These tooling options support object recovery, scientific sampling, sediment collection, archaeological investigation, marine debris removal, and underwater inspection and intervention.
The Boxfish Multitool integrates with the Boxfish Control Station, allowing operators to control its interchangeable end effectors through the same interface used to operate the ROV, without requiring additional control hardware.
Electrically actuated, the system supports PWM and RS232/485 communications, operates from 12–18 V and has a power consumption of 6 W. It is rated to depths of 1,000 metres and operates in temperatures from -35°C to 45°C, with an AL6061-T6 aluminium body.
The Multitool is compatible with Boxfish Alpha, Boxfish ROV and Boxfish Luna, as well as most ROV platforms. By allowing end effectors to be changed according to mission requirements, it provides a common tool platform for a range of underwater recovery, sampling and intervention tasks.