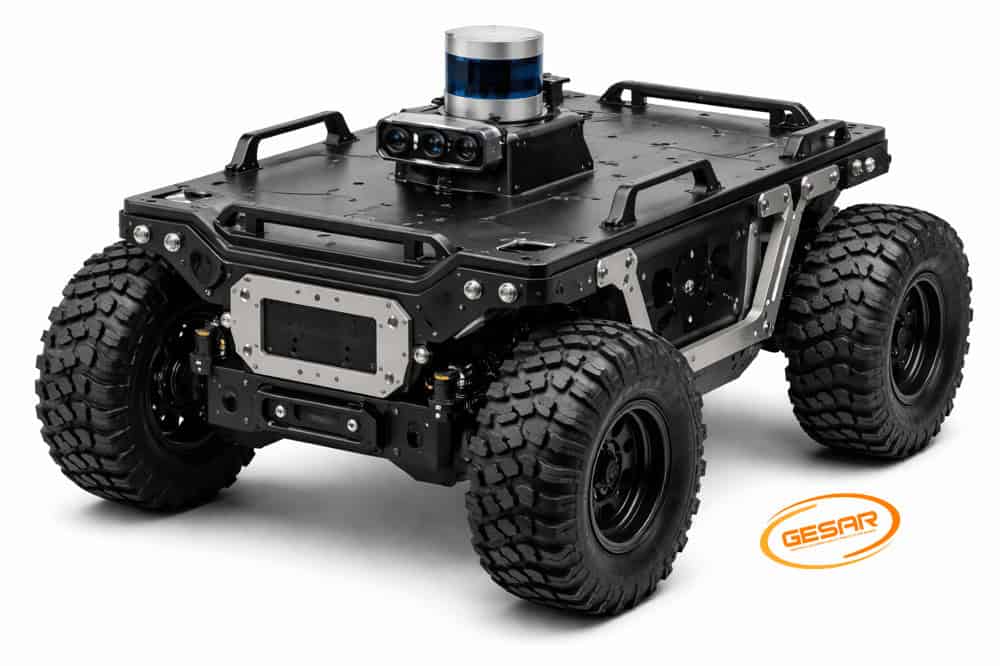
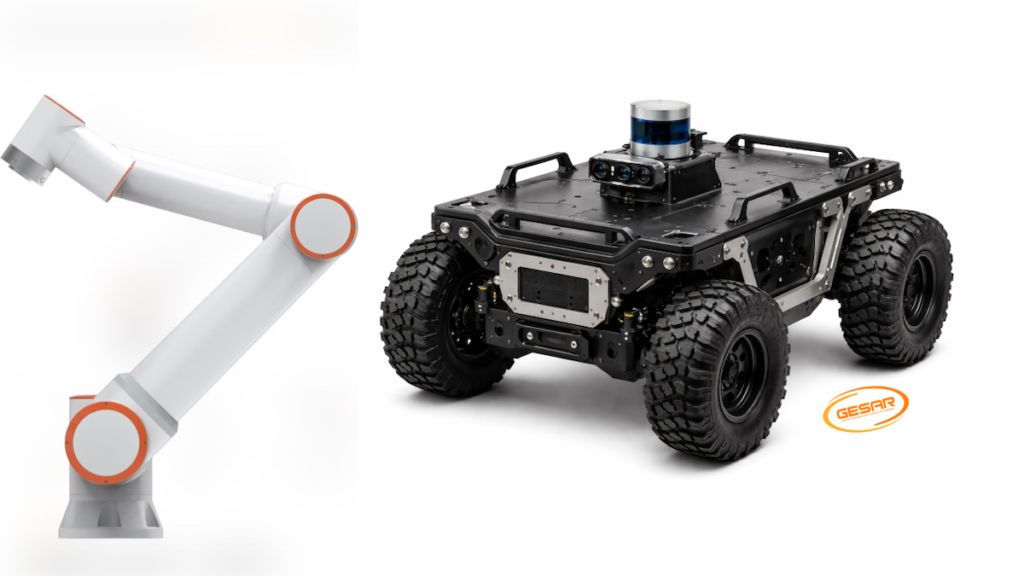
Robotic system integration specialist GESAR INC. has recently developed a line of custom four-wheel Unmanned Ground Vehicle (UGV) chassis engineered specifically to host and mobilize Fairino’s open-architecture collaborative robot platforms.
Collaborative robots have traditionally been deployed in stationary factory environments, but these automation models are less suited to tasks requiring mobility across unstructured, high-risk or outdoor terrain. GESAR combines Fairino’s high-payload, low-latency collaborative arms with rugged, teleoperated mobile infrastructure, enabling operators to carry out precise physical tasks from a safe distance.
At the core of the system is GESAR’s proprietary four-wheel UGV chassis, which can be configured to customer-specified payload capacities, speed limits and operating environments. Skid-steer, or “tank mode,” maneuverability enables the chassis to operate in confined spaces and across challenging outdoor terrain.
GESAR builds each chassis natively on a ROS 2 framework to support unified data pipelines. Fairino cobots, which feature developer-friendly open-source SDKs and API-driven motion control, can be integrated with the vehicle’s onboard computing architecture.
According to GESAR, the resulting system supports sub-millisecond real-time coordinate handoffs, 2D and 3D LiDAR mapping, and adaptive simultaneous localization and mapping (SLAM) under severe communication constraints or in GPS-denied environments.
The platform is intended for applications across several sectors:
- Industrial Logistics & Facility Operations: The mobile manipulators can autonomously navigate warehouses while using Fairino arms to manipulate industrial valves, open heavy containment doors and sort materials on dynamic facility floors.
- Non-Destructive Testing (NDT) & Inspection: In hazardous oil, gas and energy infrastructure environments, the UGV can traverse rough terrain and position Fairino arms equipped with ultrasonic, eddy-current or thermal NDT sensors against critical structural components with millimeter precision.
- Precision Agriculture: The ruggedized four-wheel chassis is designed to operate across muddy, uneven row-crop fields, while the integrated cobot can carry out tasks including autonomous pruning, selective harvesting and targeted crop-health sampling.
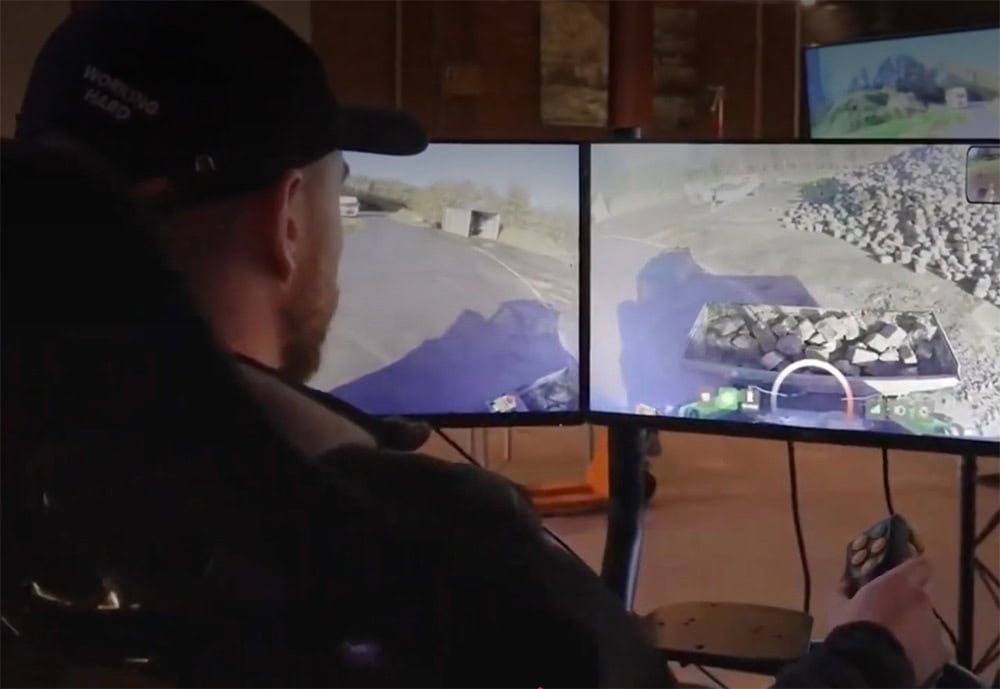
- Construction & Remote Material Handling: In high-risk construction zones, mining operations and hazardous-material environments, operators can use low-latency teleoperation to command the UGV and cobot arm to handle materials, deploy field sensors or assist with heavy-machinery setups from a remote command station.
GESAR also offers end-to-end virtual validation before physical components are manufactured. Using Fairino’s official 3D digital assets, the company develops simulation layouts based on a customer’s application description, target payload weights and operating terrain.
The mobile platform can be configured with systems ranging from lightweight inspection arms to heavy-duty 30 kg payload variants.