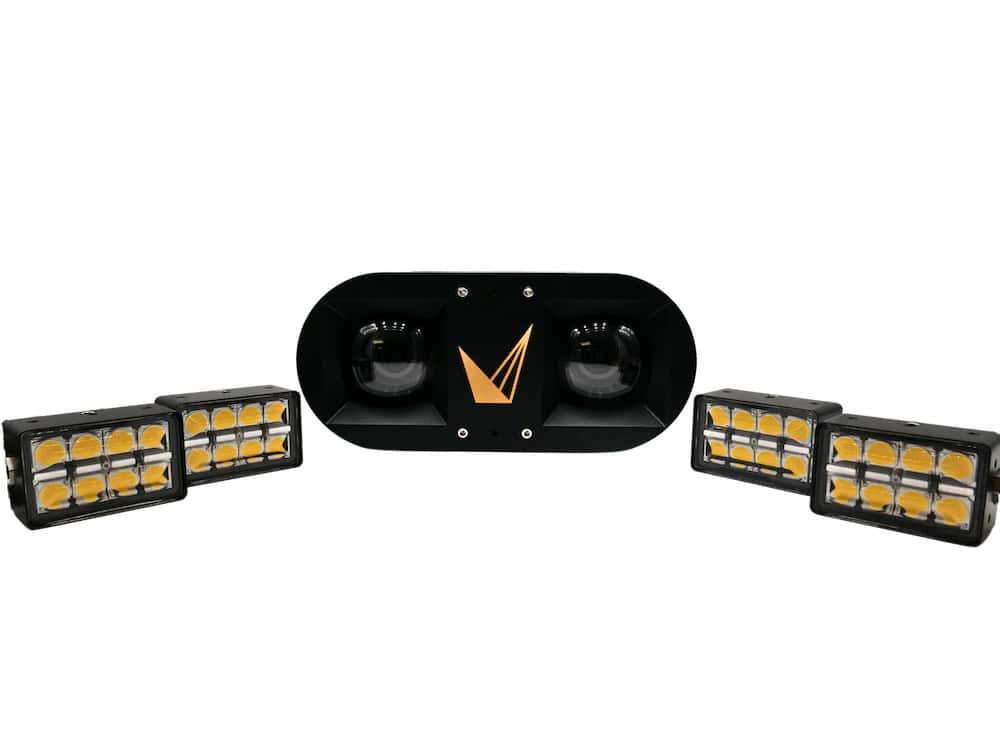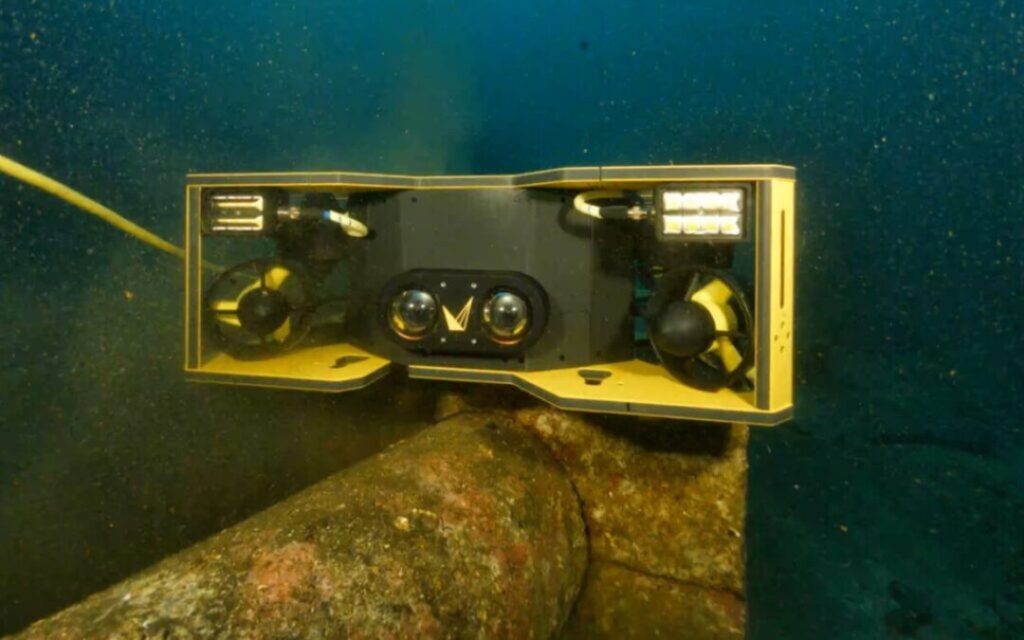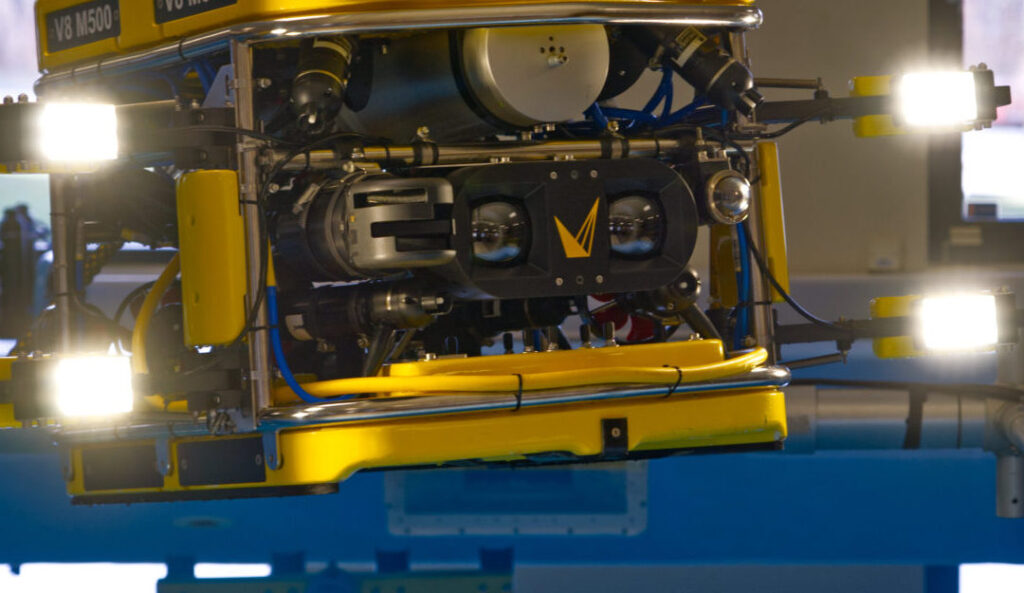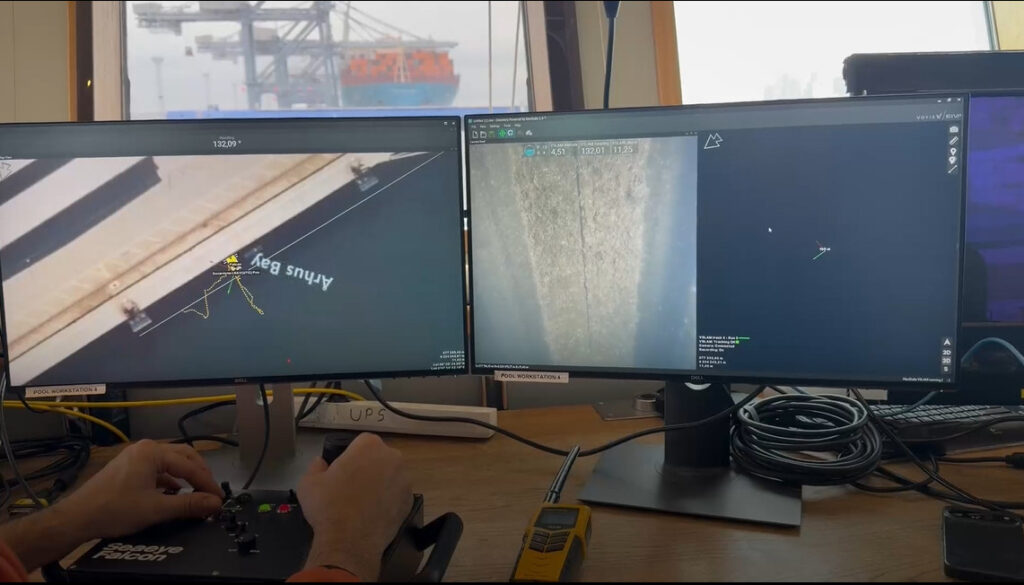
Accurately judging distance and positioning remains a challenge for remotely operated vehicle (ROV) pilots working around subsea structures, particularly in environments with limited visibility. The Discovery Stereo Perception Series from Voyis addresses this challenge by combining synchronized depth and video streams, providing operators with additional spatial information to support navigation, positioning, and underwater inspections.
Although high-quality camera footage is essential for subsea surveys and inspections, conventional video provides a two-dimensional representation of the underwater environment. Operators must interpret visual cues to estimate distances, assess orientation, and determine proximity to surrounding objects.
These limitations become particularly significant when navigating confined spaces, approaching assets for detailed inspection, or maintaining a consistent distance from structures. The need for continuous visual interpretation increases operator cognitive load and can introduce inefficiencies into ROV operations.
Integrating Depth Maps into ROV Camera Systems
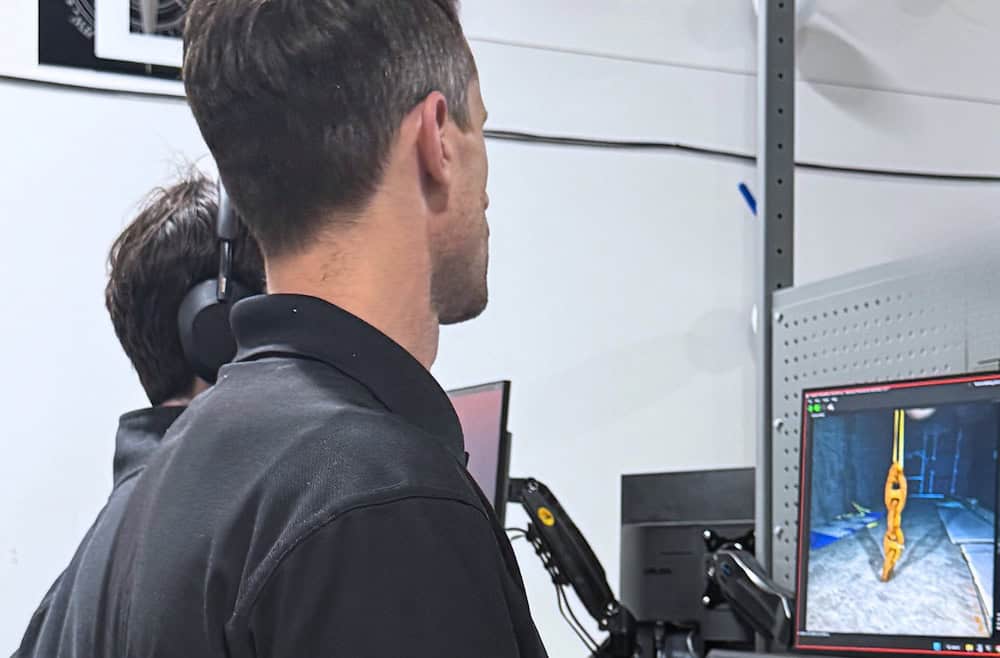
Depth maps provide an additional source of information by introducing real-time distance measurements into the camera view. Each pixel contains information about how far the corresponding object or surface is from the ROV, allowing operators to assess spatial relationships without relying exclusively on visual estimation.
This capability is particularly relevant to close-range inspection tasks, where maintaining precise positioning relative to subsea assets is important.
By making distance information available alongside camera imagery, depth maps can reduce uncertainty when approaching structures, assessing clearances, and adjusting the ROV’s position during inspection activities.
Combining Visual Information with Spatial Measurements
Depth measurements and conventional video serve different but complementary purposes in underwater navigation.
Camera imagery allows operators to identify structures, recognize features, and interpret their surroundings. Depth information provides the corresponding spatial context, helping operators understand the distance between the ROV and objects within the camera’s field of view.
Neither information source provides the same level of context independently. Depth data without clear imagery can make it difficult to interpret what is being measured, while video alone requires operators to estimate distances based on visual cues.
The [Voyis Discovery Stereo Perception Series](https://voyis.com/discovery-stereo-perception-series/) applies this combined approach, delivering synchronized depth and video streams to support real-time operational decisions.
Providing both types of information within a single system allows ROV pilots to assess visible features alongside their relative distances, reducing the need to make assumptions about positioning in complex subsea environments.
Extending Situational Awareness Through a Wide Field of View
Camera field of view is another important consideration in ROV piloting. A narrow viewing angle limits the surrounding context available to operators, potentially making it more difficult to assess nearby structures and obstacles.
A wide field of view captures more of the underwater environment within each frame, allowing pilots to observe a broader area while navigating around assets or conducting inspections.
When depth measurements extend across this wider scene, operators gain spatial information beyond the central portion of the image. This provides additional context for assessing distances to surrounding objects and understanding the ROV’s position relative to nearby structures.
The combination can support smoother navigation, improved alignment with inspection targets, and more controlled maneuvering during subsea surveys and inspections.
Improving Underwater Visibility with Image Enhancement
The quality of underwater camera imagery can be affected by several environmental factors, including low light, water turbidity, and backscatter. These conditions can obscure structural details and make it harder for operators to interpret the surrounding environment.
Image enhancement techniques help address these challenges by improving contrast, sharpness, and overall image clarity.
Clearer imagery is particularly useful when combined with depth information, as operators need to understand both the visible scene and the spatial measurements associated with it.
Enhanced video and depth data therefore provide complementary information for maintaining situational awareness in conditions where conventional ROV camera footage may be difficult to interpret.
Supporting More Consistent ROV Positioning and Inspection
Integrating depth maps, enhanced video, and a wide field of view within a unified camera system can help operators make more informed piloting decisions without continually switching between separate sources of information.
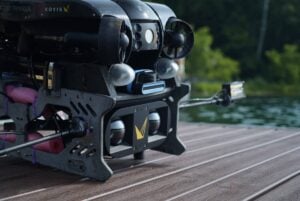
For inspection activities, the availability of real-time distance measurements supports more consistent positioning relative to subsea structures. Operators can use this information when maintaining inspection offsets, approaching assets, or maneuvering through confined areas.
The combination also has implications for piloting efficiency. Reducing dependence on visual distance estimation can help limit the number of judgment calls required during navigation, while improved visibility and broader spatial context support more stable and precise vehicle control.
Together, these capabilities can contribute to more efficient subsea inspections and surveys by giving operators a clearer understanding of the ROV’s immediate surroundings.
Moving Beyond Conventional Video-Based Piloting
ROV camera systems are increasingly being considered not only as tools for visual observation, but also as sources of spatial information that can support operational decision-making.
Combining depth measurements with enhanced video provides a more complete representation of the underwater environment than either information source can offer independently.
With distance information available across a wide field of view, ROV pilots can better assess their proximity to structures, interpret their position, and make navigation adjustments based on both visual and spatial data.
This approach supports a shift from piloting based primarily on visual estimation toward more informed control during complex subsea inspection and survey operations.