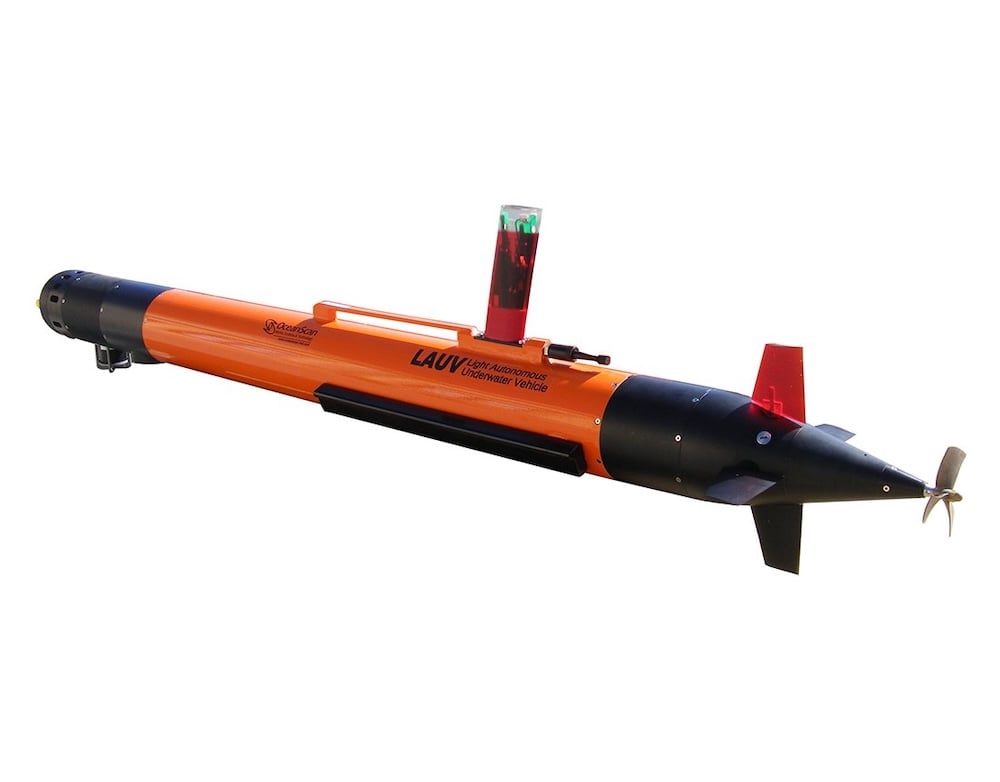
LAUV Light Autonomous Underwater Vehicle
One-person portable AUV with low logistical footprint
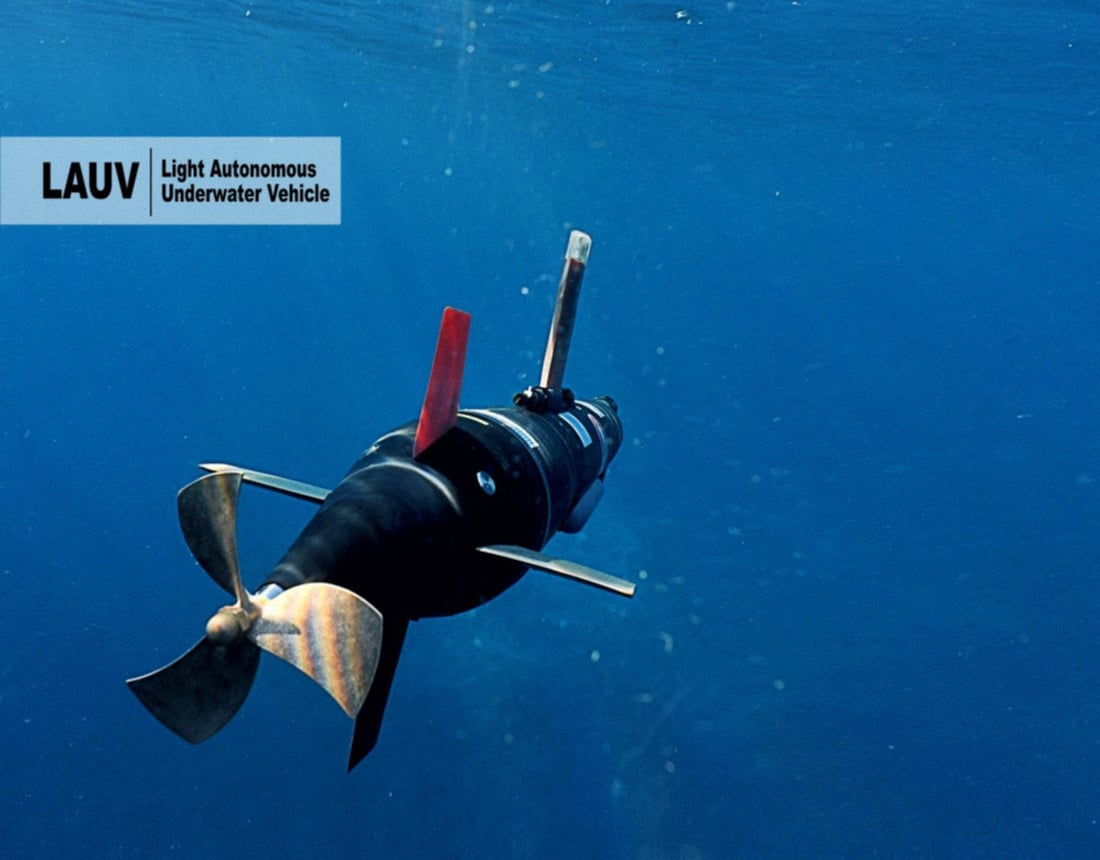
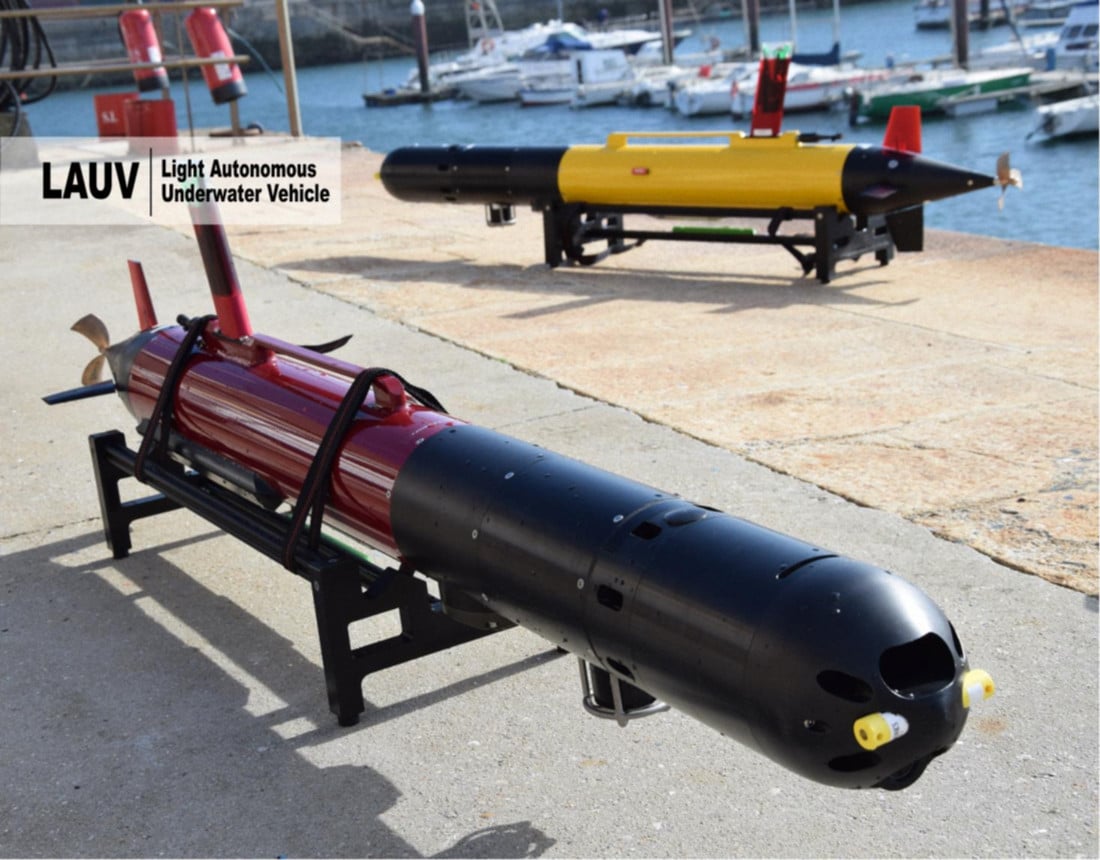
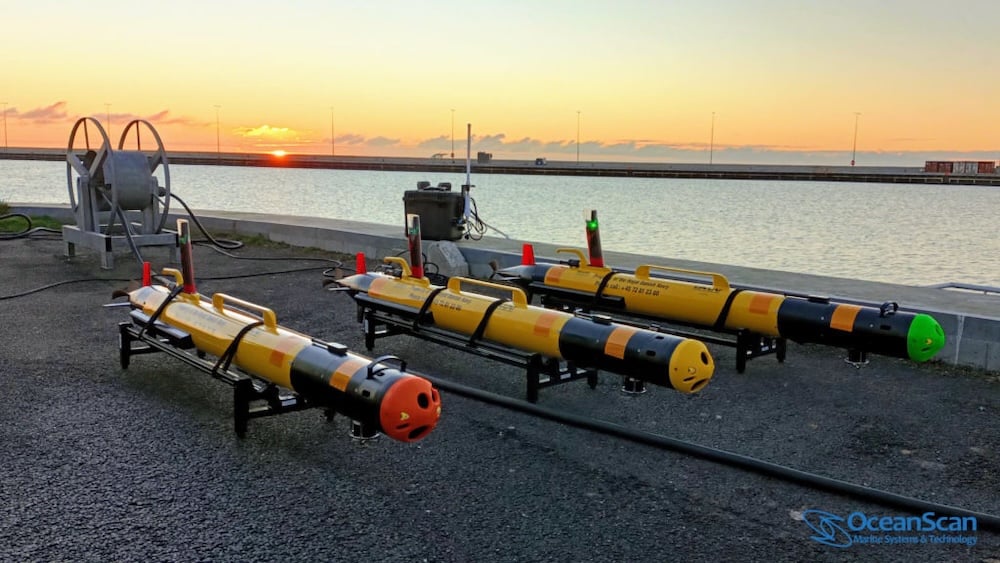
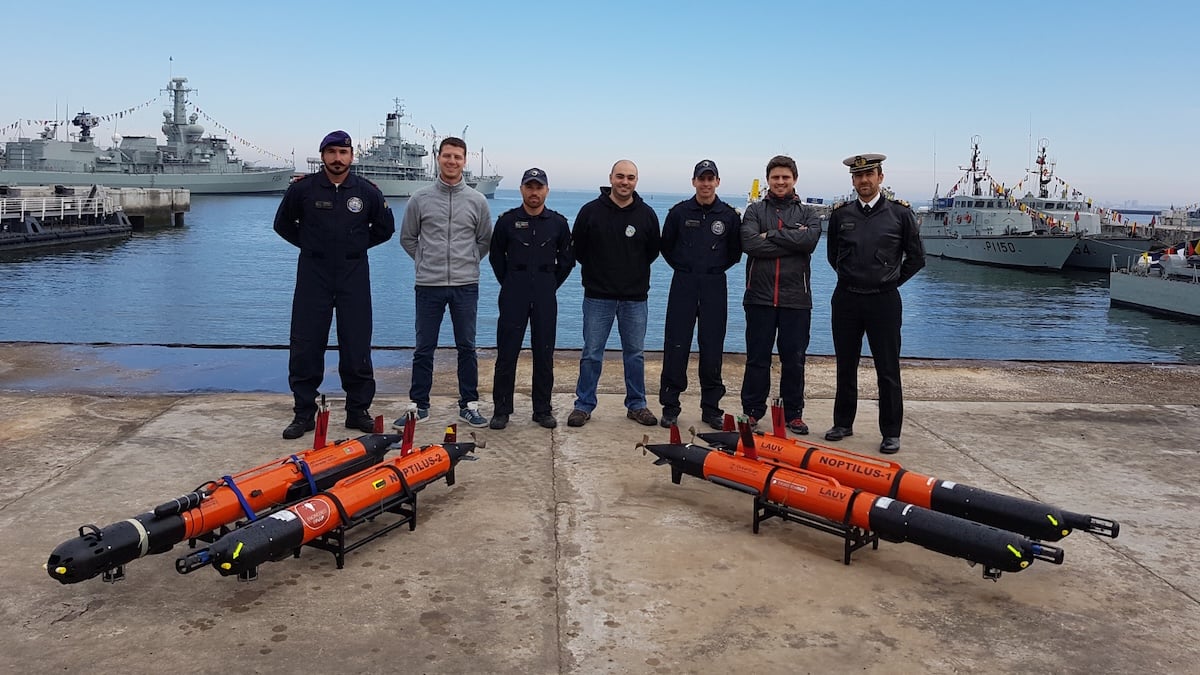
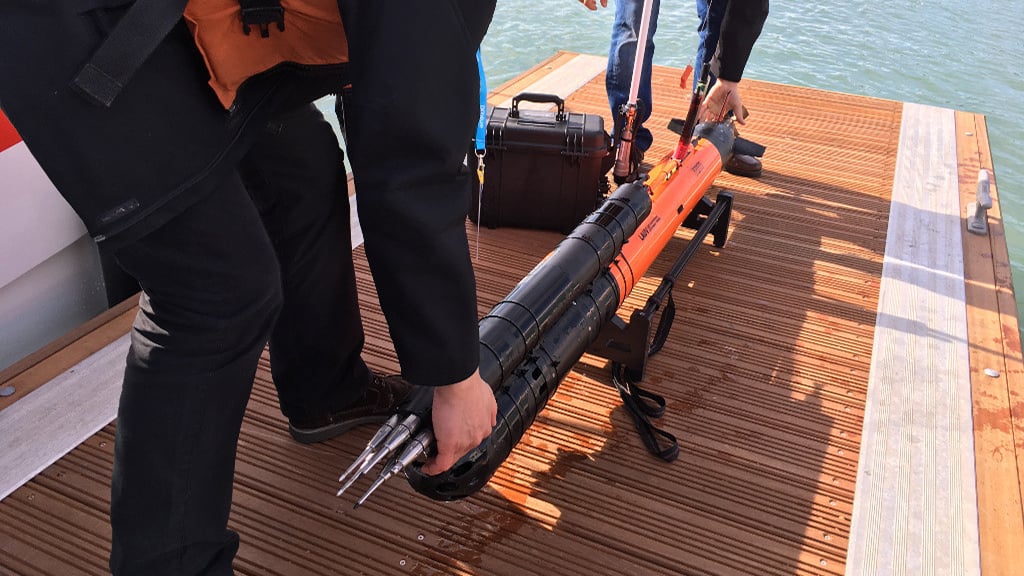
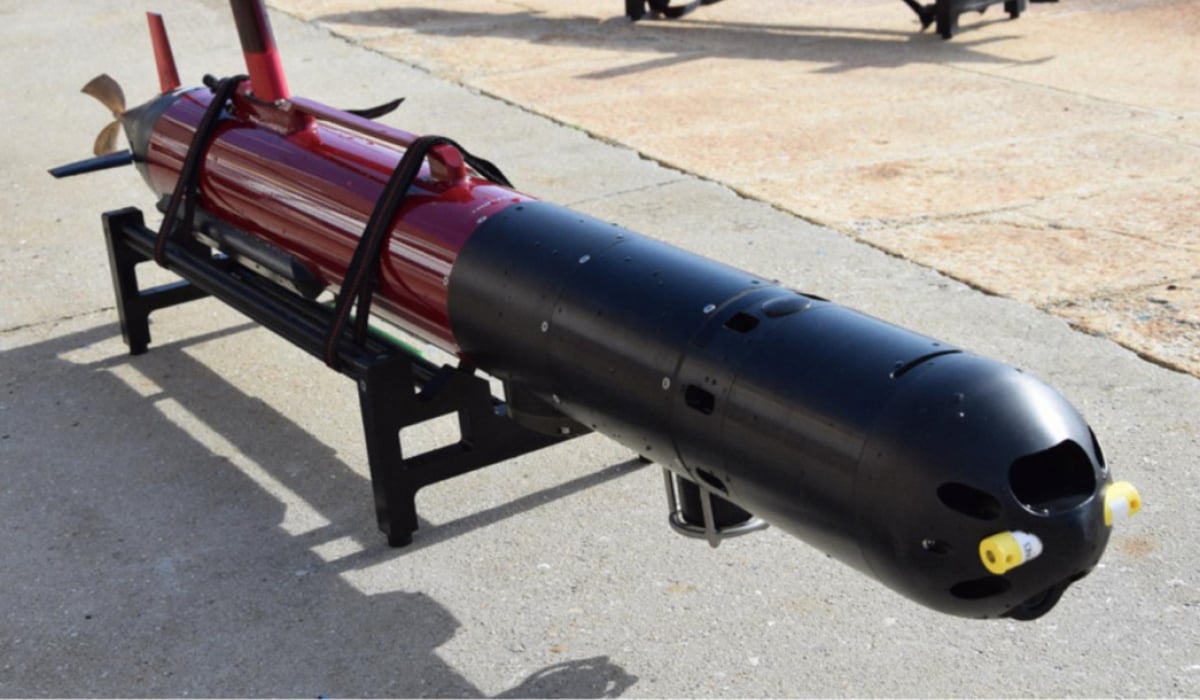
The LAUV is a lightweight and cost-effective autonomous underwater platform that is designed for deployment, operation and recovery by a single person. Its compact form allows launch from shore, a pier or a small boat without cranes or specialized tools, and a laptop and portable communications hub provide a simple operational setup for one or more vehicles.
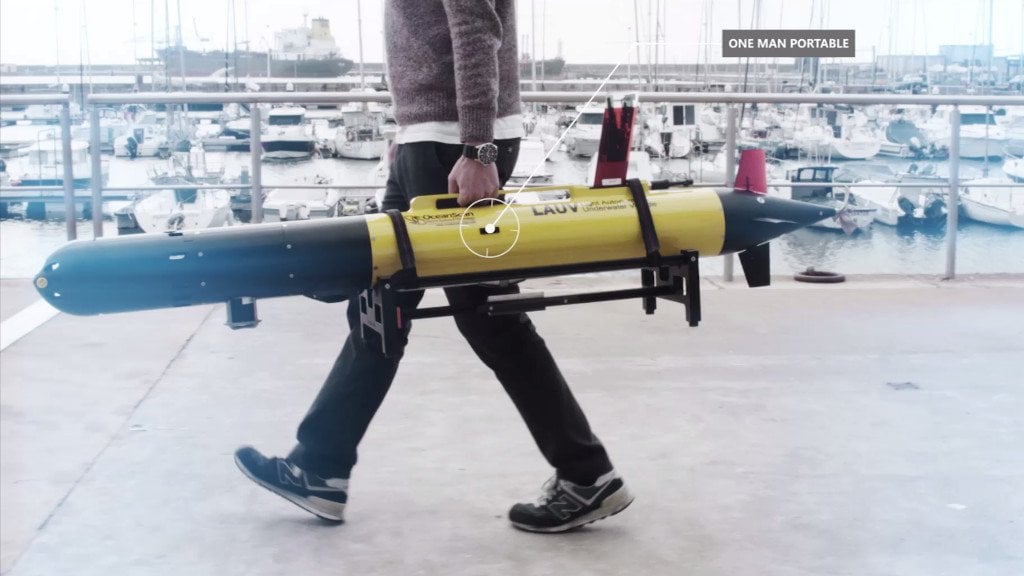
Ideal for oceanographic and hydrographic surveys, environmental monitoring, and security and surveillance missions, the LAUV has accumulated thousands of operational hours in deployments worldwide. Its open architecture enables users to integrate additional instruments, actuators, algorithms and behaviors, adapting the platform to their research and survey requirements.
Key specifications include:
 Dimensions: 115–250 cm long; 15 cm hull diameter
- Weight in Air: 15–35 kg
- Depth Rating: 100m & 400m options
- Top Speed: 6 knots
- Endurance: >8 hours at 3 knots typical
Modular design & payload options
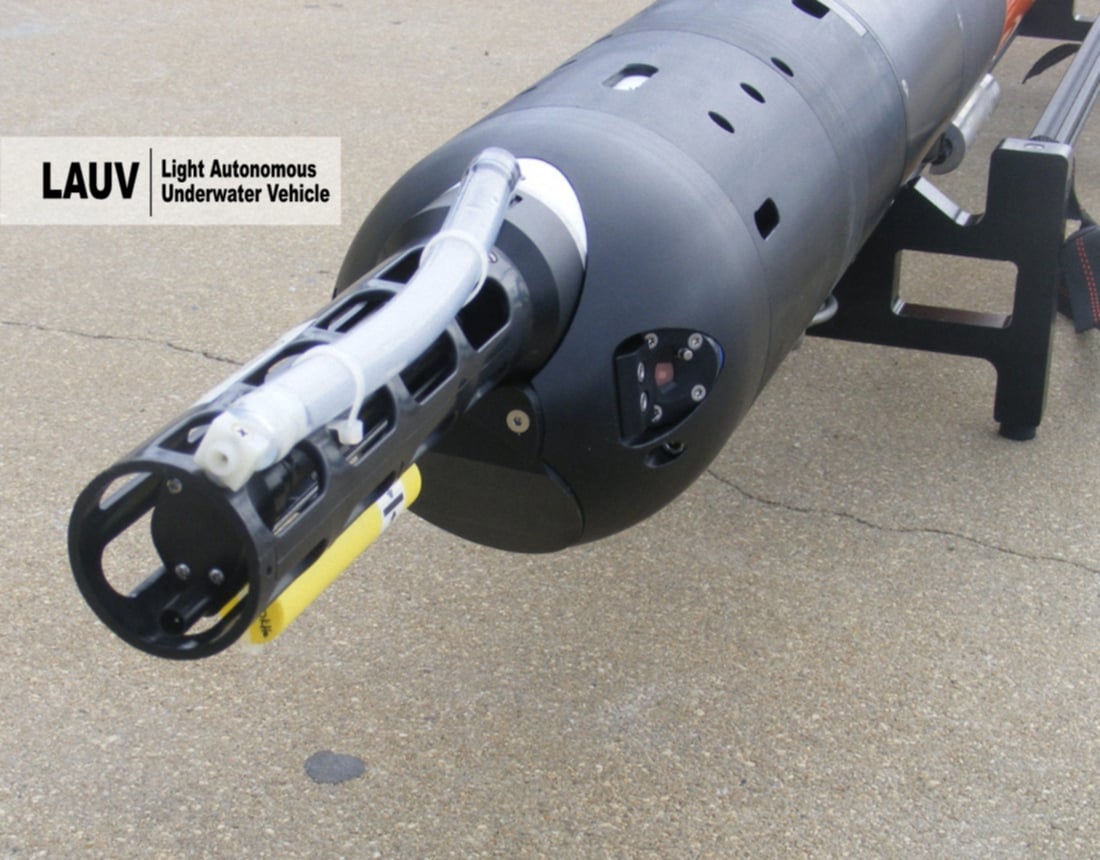
Thanks to its modular design and open source software suite, the LAUV can be equipped with a wide variety of different combinations of sensors, payloads and onboard equipment. OceanScan-MST can configure each system during production, selecting navigation, communications, imaging and scientific payload options to match the intended mission.
An external ballast rail allows weights to be easily added or removed, tailoring the vehicle for fresh or saltwater operations.
Mission Planning & Vehicle Control
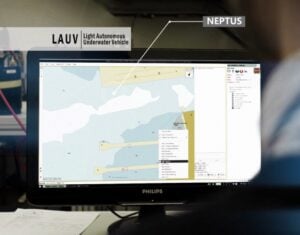 LAUV’s operator console can be set up on a regular or rugged laptop or PC running OceanScan-MST’s Neptus command and control software. This provides operators with an intuitive solution that covers all stages of the mission lifecycle, including configuration, planning, simulation, execution and post-mission data analysis.
The LAUV Remote app allows users to teleoperate the vehicle and check its status from a smartphone. For operators who prefer physical controls, a joystick can also be connected to the computer running Neptus.
Manta Communications Gateway
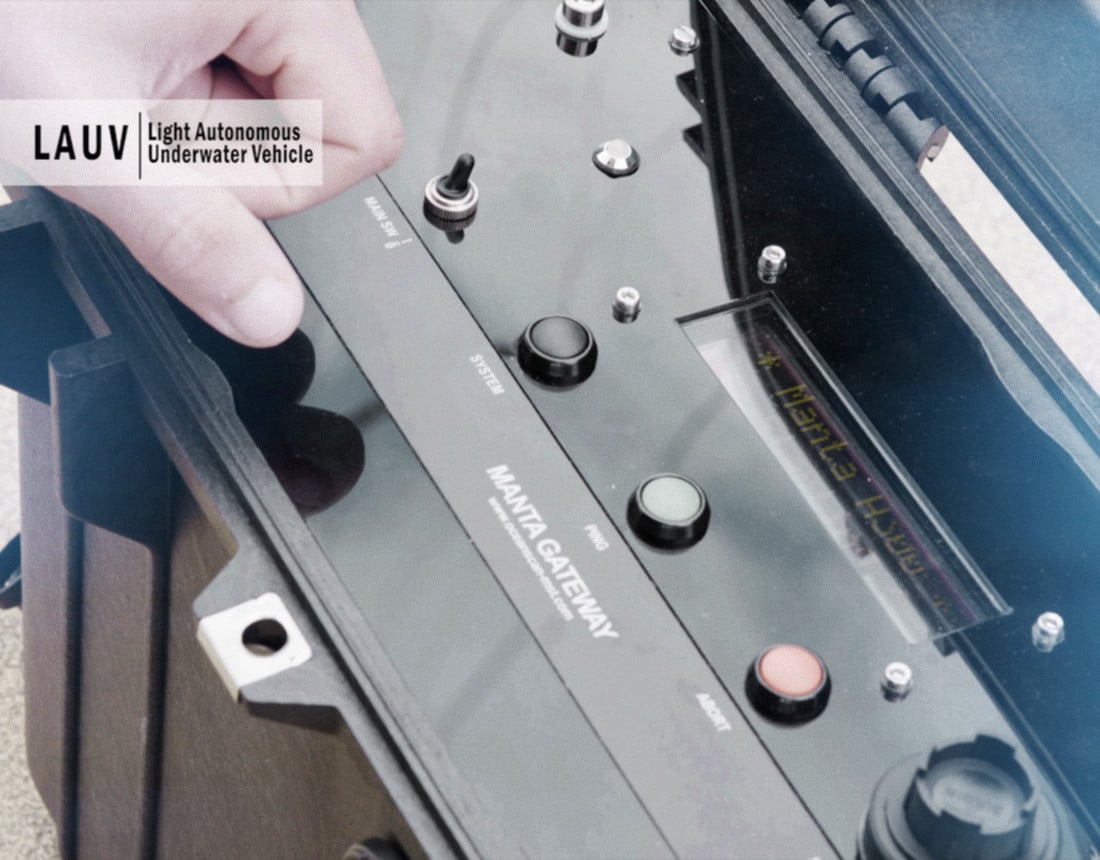
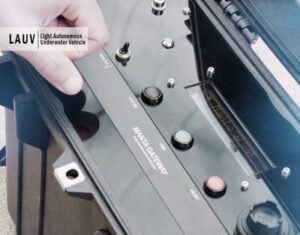 Manta is a portable, battery-powered communications hub linking operators and one or multiple LAUVs through wireless and acoustic connections. Its rugged, waterproof enclosure allows installation on a buoy or operation from an open vessel such as a RHIB.
Configuration options include extended-range Wi-Fi for surface communications, an acoustic modem for underwater messaging, cellular connectivity, and Iridium satellite communications. An integrated GPS receiver can display the gateway’s position on the mission map, which is particularly useful during vessel-based operations.
 verified
This business has been claimed by OceanScan-MST and verified by UST.