



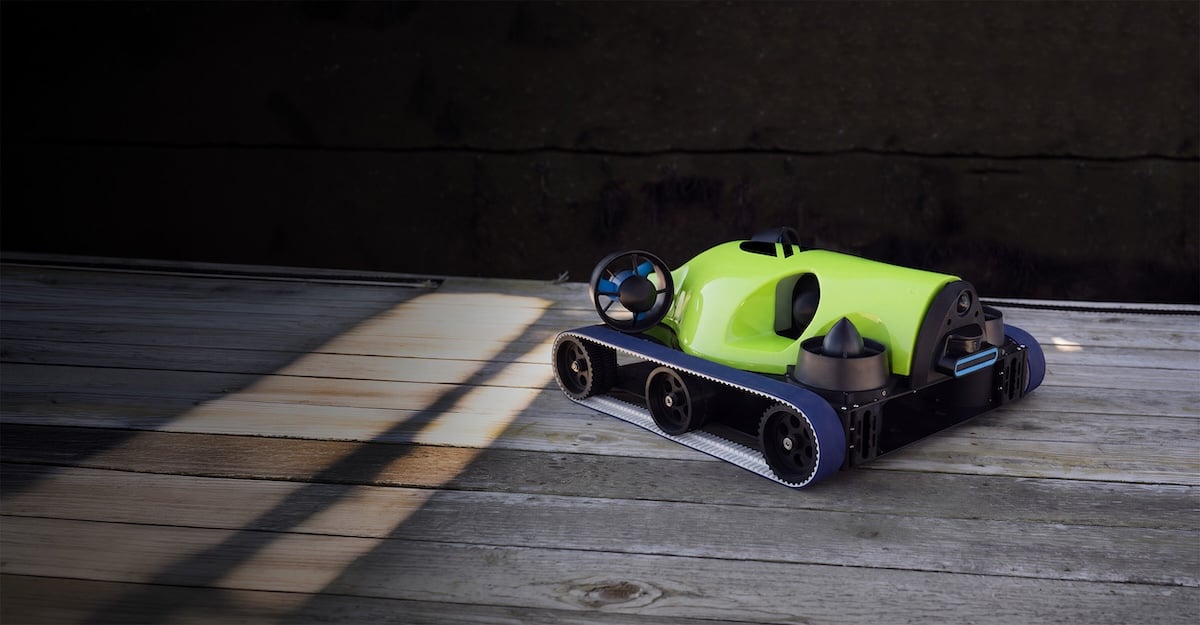
Bayonet Sweep is an agile hull crawling robot developed for rapid underwater inspection by navies, security teams, and port and harbor authorities.
The vehicle can operate in free-flight mode or attach directly to a hull using non-magnetic vortex adhesion, supporting both submerged visual inspection and close-contact hull examination. Forward and aft HD cameras, high-resolution multibeam sonar, obstacle detection and avoidance, hull mapping, and high-precision inertial navigation support autonomous inspection and navigation, including operations where underwater visibility is limited.
Sweep combines inspection, anomaly detection, classification, operator notification, and georeferenced reporting within a single workflow. Real-time camera feeds and vehicle information are presented through Greensea Core and Bayonet Workspace, giving topside personnel visibility into detected objects and vehicle operation. Its portable format supports rapid deployment, while multiple vehicles can operate independently across separate areas of a hull. A modular chassis also enables custom payload configurations for specialized uncrewed inspection requirements.
Specifications:
| Dimensions: | 76.2 × 55.8 × 25.4 cm (L × W × H) |
| Dry weight: | 25.8 kg |
| System input voltage: | 120 or 240 VAC |
| Peak power: | 1750 W |
| On-hull operation: | Up to 3 knots |
| Software / user interface: | Greensea Core / Bayonet Workspace |






