
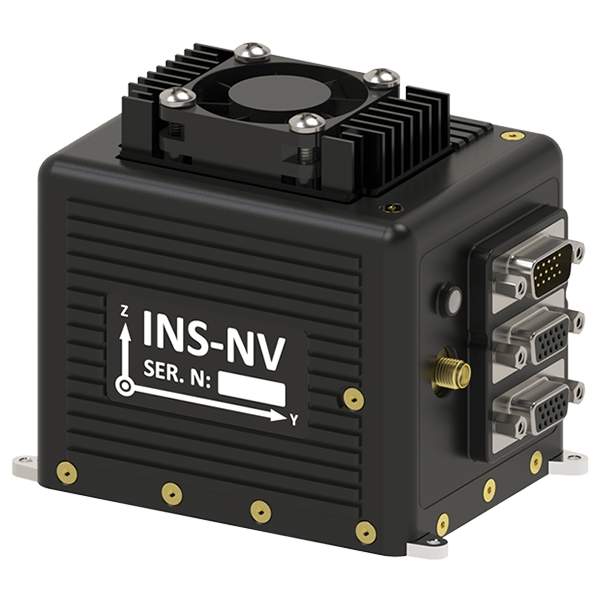
The Inertial Labs INS-NV combines an inertial navigation system, attitude and heading reference functionality, and an NVIDIA Jetson compute module within a modular development platform for advanced navigation processing.
Designed to host computationally intensive algorithms, the INS-NV supports machine vision, autonomous guidance, sensor fusion, and alternative positioning, navigation, and timing development. Tactical-grade MEMS accelerometers and gyroscopes are fully calibrated, while the integrated multi-constellation GNSS receiver supports GPS, QZSS, GLONASS, Galileo, BeiDou, and NavIC. The platform also incorporates a barometric altimeter, in-flight magnetometer calibration, MIL-STD-810G compliance, and an ASPN-compatible data interface available upon request.
INS-NV is engineered to shorten integration cycles for developers building uncrewed and autonomous systems that require dependable real-time navigation.
Inertial Labs sensor-fusion processing, aiding-source support, calibration capabilities, and navigation algorithms provide position, velocity, timing, and attitude data while preserving orientation performance when GNSS becomes unavailable. External aiding sensors can be incorporated into the fusion architecture, and the platform supports commercial off-the-shelf cameras as well as Inertial Labs sensor modules. Raw GNSS observations and IMU measurements are also available for post-processing, giving developers additional flexibility when evaluating navigation, vision, autonomy, and APNT algorithms.






