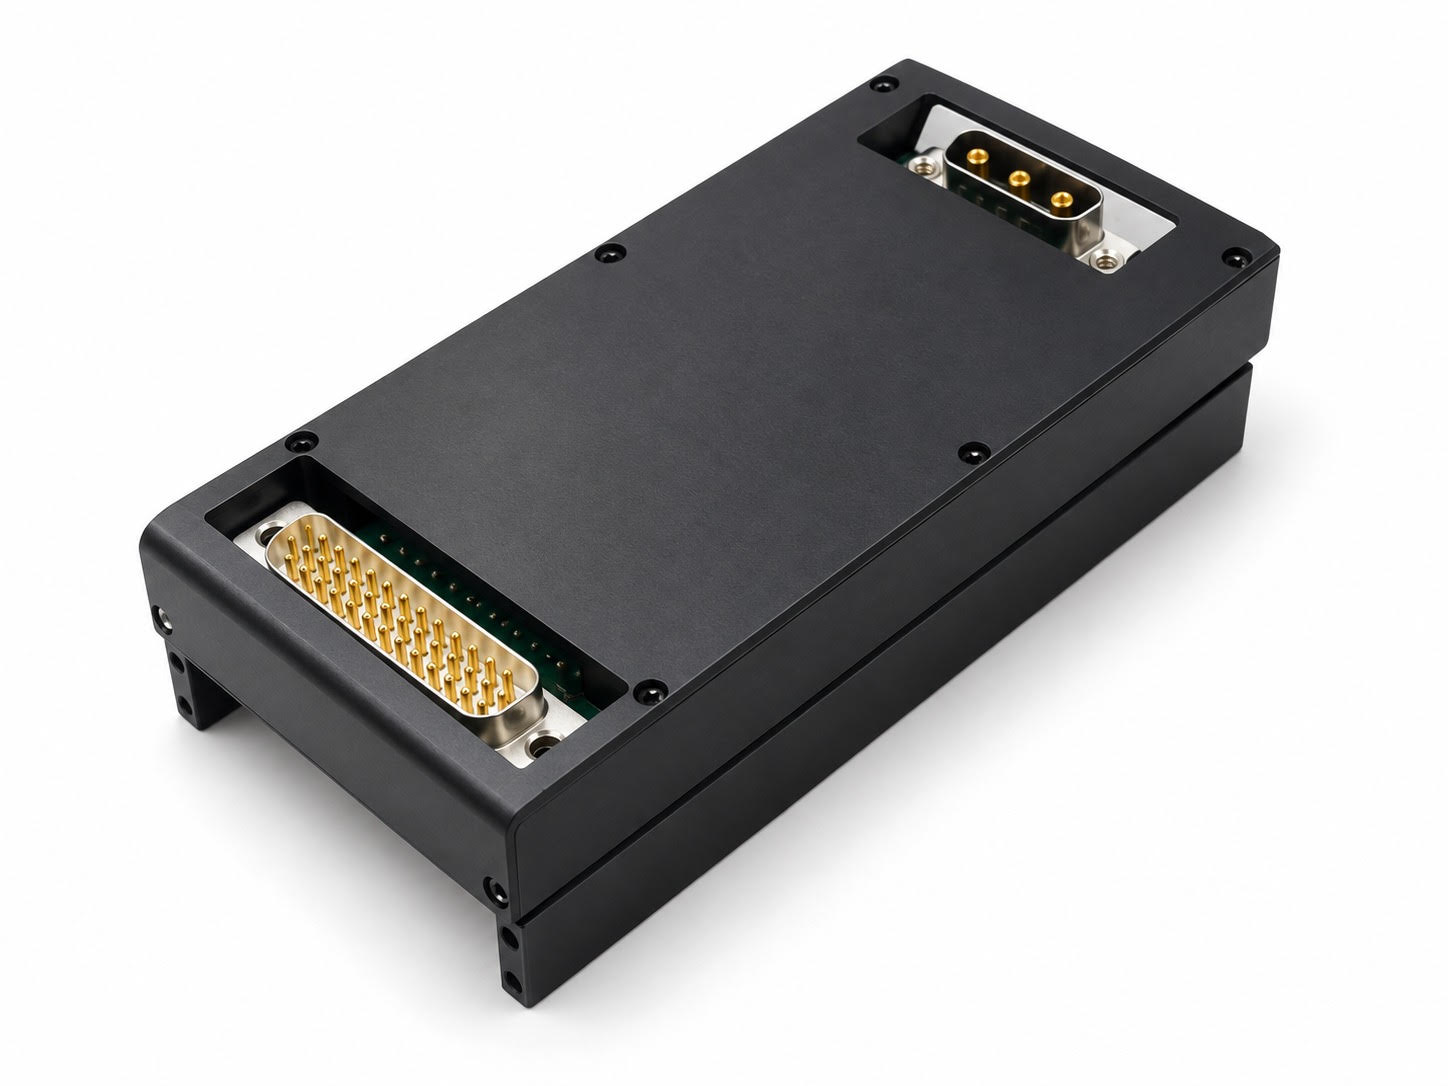
The SGT-FDMSCK-YKD-AA is a field-oriented-control motor driver developed for precise position control of three-phase BLDC actuation motors. Its control architecture combines a cascaded position PID loop with current PI regulation, supporting accurate motor positioning and adaptable integration into aerospace, defense, unmanned and robotic actuation systems.
The driver supports A/B/Z encoder and Hall-effect sensor feedback, with software-defined position limits and user-defined encoder zero. PID/PI parameters can be updated during operation, allowing the controller to be adapted to different actuator mechanics and control-system requirements.
RS-422 and CAN interfaces support system-level integration, while integrated telemetry provides position, measured speed, Iq current, DC bus voltage and board temperature data. Command and telemetry communications incorporate CRC-16-CCITT protection for data integrity.
Safety and control functions include emergency stop, system enable, braking and position-limit management. The controller operates from a 20–34 VDC bus input, with software-based bus-current protection and undervoltage torque derating.
| DC bus input | 20–34 VDC |
| Control architecture | Cascaded Position PID → Current PI |
| Commanded variable | Motor target position in encoder counts |
| Motor output | Three-phase BLDC: U / V / W |
| Position feedback | A/B/Z encoder |
| Hall feedback | H1 / H2 / H3 |
| Communications | RS-422; CAN |
| RS-422 configuration | 115200 baud, 8 data bits, no parity, 1 stop bit |
| Telemetry | Position, speed, Iq current, DC bus voltage, temperature |
| Telemetry period | 10 ms default; configurable 5–10,000 ms or disabled |
| Auxiliary power | 3.3 V / 100 mA; 5 V / 200 mA |
| Data integrity | CRC-16-CCITT (XMODEM) |
| Software bus draw limit | 8 A* |