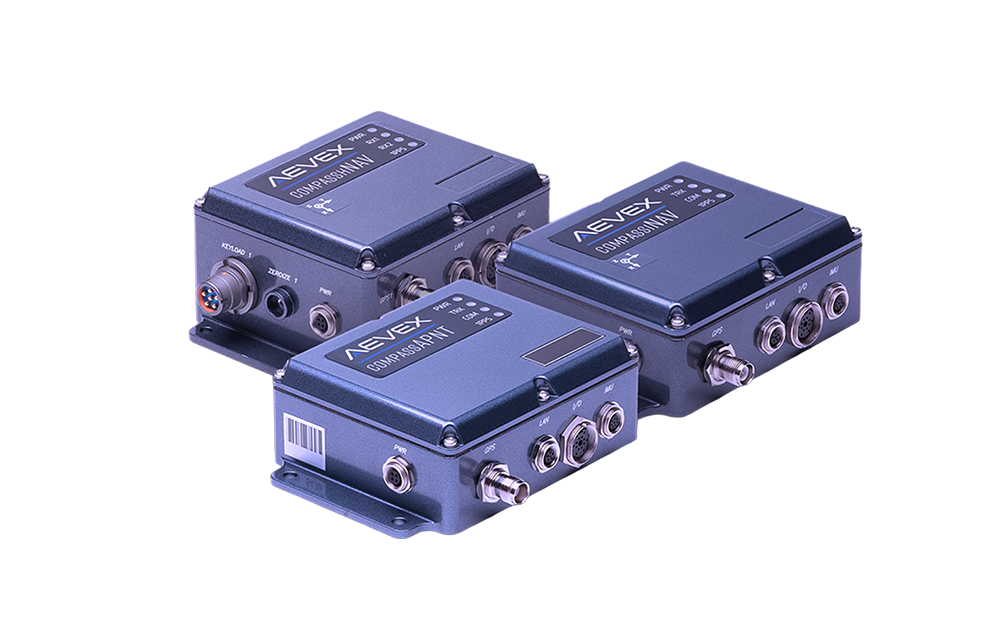
AEVEX CompassPNT is a family of advanced assured position, navigation, and timing solutions designed to sustain precise navigation when GPS is degraded or unavailable. Developed for air, land, and sea platforms, the systems combine multi-sensor fusion, Kalman-filtering techniques, relative navigation, integrated timing, and high-speed positioning to maintain dependable PNT data during demanding missions. CompassPNT supports both manned and autonomous systems, providing the continuity required where consistent positioning and timing are critical to platform operation.
CompassAPNT integrates a high-performance GPS master clock with an advanced inertial navigation system, delivering continuous positioning and timing data from one compact unit. Consolidating these functions reduces size, weight, and power requirements while retaining accurate output for dynamic platforms. Navigation solutions are generated at 100 Hz through Ethernet and RS-232 interfaces, alongside raw GPS and IMU recording for post-processing. The system also provides configurable timing outputs, PTP Grandmaster and NTP server functionality, web-based configuration and monitoring, and built-in compatibility with multiple commonly used IMUs.
| Size: | 33.8 in³ (4.73 × 3.95 × 1.81 in) |
| Weight: | 20 oz. |
| Power: | 10–30 VDC @ 2 A minimum, excluding external IMU |
| Specified temperature: | -20°C to +65°C |
| Operating temperature: | -40°C to +70°C |
| Interfaces: | External power, TNC GPS antenna, 1 Ethernet port, 3 RS-232 serial ports, timing I/O, 10 MHz clock, and 4 status LEDs |
| Navigation output rate: | 100 Hz via Ethernet and RS-232 |
| Solution latency: | 16 microseconds 1δ |
| Data logging: | Navigation solutions, raw GPS data, and raw IMU data for post-processing |
| Supported IMUs: | Honeywell HG19001, HG1930, HG17001, and HG99001; Northrop Grumman LN2001; KVH 1725, 1750, and 1775; other IMUs available upon request |
| Web interface: | Status, configuration, logging, and software updates |