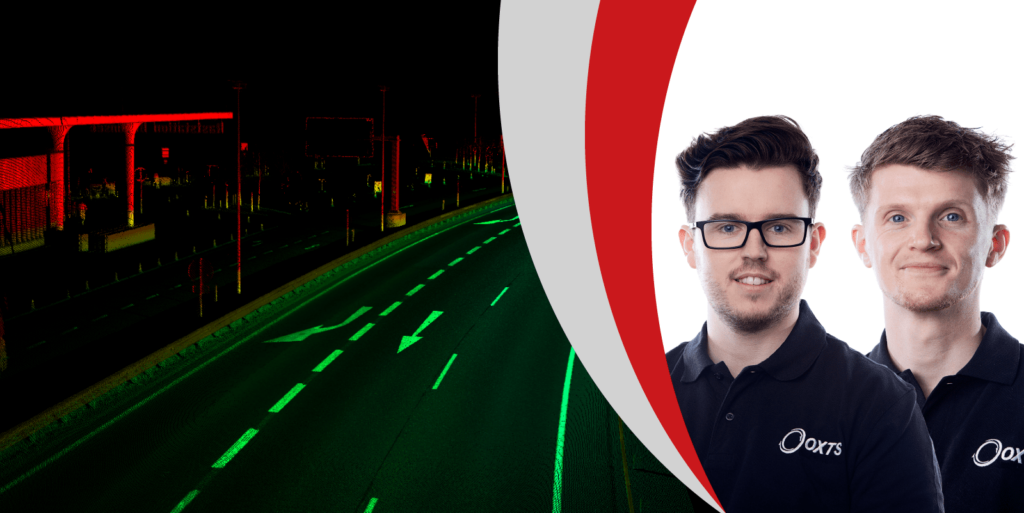
The environment for automotive testing is rapidly changing and the challenge to get centimetre-accurate groundtruth and reference data seems more difficult than ever.
However, through advanced sensor fusion techniques, using sensors such as LiDAR, engineers can increase the amount of time spent with centimetre-level position accuracy – irrespective of the environment.
Join OxTS’ Head of Product – New Technology, Paris Austin and Senior Product Manager, Peter Rylands live at 14:00 hrs (BST) on Tuesday, 28th June as they share insights with attendees and discuss:
- The challenges associated with gaining accurate positioning for vehicle validation, using advanced sensor fusion techniques (with a focus on LiDAR)
- How the concept and approach to the problems faced by our customers is driving development
- The work underway within OxTS R&D to put this innovative solution into the hands of users
During the webinar, real world data will be shown from early prototypes, while relating the results back to the challenges users are facing on a daily basis.
The webinar is free to attend, and registrants will receive a copy of the recording after the event.